

RoboCup
RoboCup (short for Robot World Cup) is an international scientific initiative and annual competition, founded in 1997, that uses the game of soccer as a standard problem to drive research in artificial intelligence, robotics, and multi-agent systems.[1] Widely described as the world's largest robotics and AI competition, it grew from about 40 teams at the first event in Nagoya in 1997 to some 2,000 participants from 40 countries at RoboCup 2025 in Salvador, which had been previewed as more than 250 teams from 37 countries, and organizers expected more than 3,000 competitors at RoboCup 2026 in Incheon.[3][12][25][13] The federation organizes a flagship World Championship event each summer along with a network of regional Open competitions on six continents.[24]
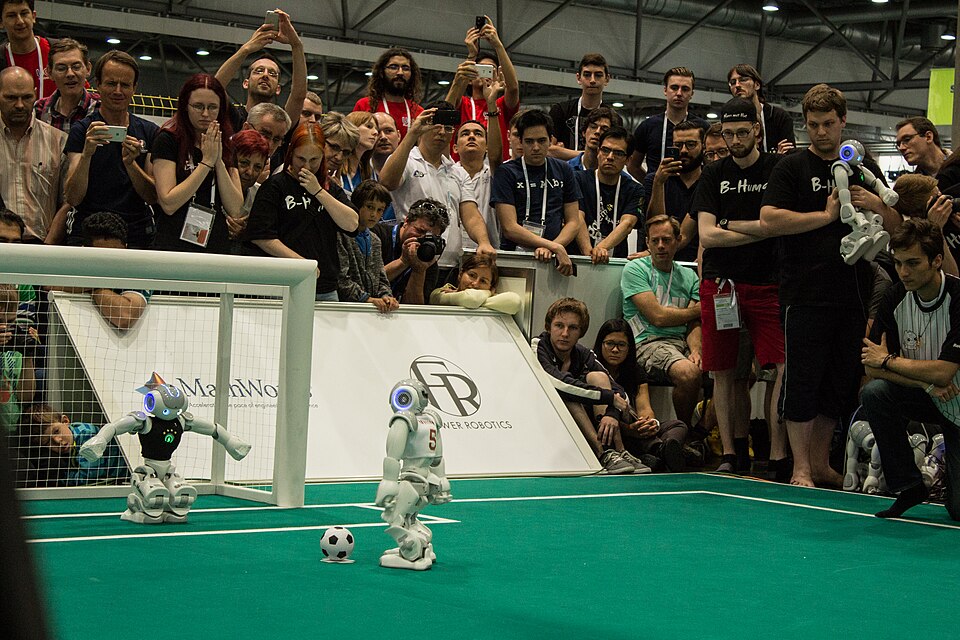
The project is defined by a single long-horizon grand challenge, stated by founding president Hiroaki Kitano: "By the middle of the 21st century, a team of fully autonomous humanoid robot soccer players shall win a soccer game, complying with the official rules of FIFA, against the winner of the most recent World Cup."[1][27] That 2050 goal, which targets a team of fully autonomous humanoid robots beating the reigning human World Cup champions, was deliberately set to be roughly as ambitious as putting a man on the Moon.[5] The pursuit of that target has produced research progress that extends far beyond soccer, including widely cited advances in probabilistic localization, real-time computer vision, multi-robot coordination, bipedal locomotion, deep reinforcement learning, and disaster response robotics.[5]
RoboCup is organized into several major divisions. RoboCupSoccer remains the original heart of the competition and contains a half-dozen sub-leagues that range from millimeter-precision wheeled robots to nearly two-meter-tall humanoids. RoboCupRescue focuses on robots that can locate victims in the rubble of urban disasters.[22] RoboCup@Home benchmarks domestic service robots in realistic apartment environments.[23] RoboCup Industrial, which historically housed the @Work and Logistics leagues, addresses smart manufacturing challenges.[17] RoboCupJunior is the educational division for primary and secondary school students. Together these divisions cover the full pipeline from K-12 outreach to graduate-level research, and the federation publishes peer-reviewed proceedings each year through Springer's Lecture Notes in Artificial Intelligence series.
What is RoboCup and when did it start?
The idea that became RoboCup grew out of a Workshop on Grand Challenges in Artificial Intelligence held in Tokyo in October 1992.[3] At that workshop, a small group of Japanese researchers led by Hiroaki Kitano, Minoru Asada, and Yasuo Kuniyoshi began discussing whether soccer might serve as a unifying problem for AI research, the way chess had served the previous generation.[3] Chess had effectively been solved as an AI showcase by the time IBM's Deep Blue defeated Garry Kasparov in 1997, and the field needed a new standard problem that demanded perception, real-time decision making, multi-agent cooperation, and physical embodiment all at once. Soccer fit the bill because it required teams of agents to act under uncertainty, in a continuous environment, against an adversary, and with no opportunity to pause and think.[1]
In June 1993 the same group decided to launch a robot competition tentatively named the Robot J-League, after the newly formed Japanese professional soccer league.[3] International interest from researchers in Europe and North America quickly pushed the organizers to widen the scope, and the project was renamed Robot World Cup Initiative, abbreviated RoboCup.[3] Kitano, Asada, and their collaborators set out the vision in "RoboCup: The Robot World Cup Initiative" (first presented around IJCAI-95 and published in the 1997 Autonomous Agents conference proceedings), and they followed it with the influential 1997 article "RoboCup: A Challenge Problem for AI" in AI Magazine.[2] That paper, co-authored by Kitano, Asada, Kuniyoshi, Itsuki Noda, Eiichi Osawa, and Hitoshi Matsubara, framed soccer as a grand challenge that would force researchers to integrate sensor fusion, multi-agent collaboration, real-time reasoning, strategy acquisition, and autonomous agent design into a single working system.[1]
The first RoboCup competition, RoboCup-97, took place in conjunction with the 1997 International Joint Conference on Artificial Intelligence (IJCAI-97) in Nagoya, Japan.[3] The federation counts over 40 teams (real robot and simulation combined) and more than 5,000 spectators, while other accounts give 38 teams from 11 countries; teams competed in three divisions: a Small Size league, a Middle Size league, and a Simulation league that ran games entirely in software.[3][25] From those modest beginnings the event grew rapidly. By RoboCup-2000 in Melbourne, Australia, RoboCupJunior had launched as an educational division, and over the following two decades the federation added the Standard Platform League, the Humanoid League, RoboCupRescue, RoboCup@Home, the Logistics League, and @Work, broadening the project well beyond soccer.[4]
RoboCup is now governed by the not-for-profit RoboCup Federation, which was originally registered in Switzerland and is currently headquartered in the United States.[35] The federation is led by an elected Board of Trustees and a network of league technical committees that maintain the rules and scientific direction of each sub-league. Manuela Veloso of Carnegie Mellon University, Daniele Nardi of Sapienza University of Rome, and Itsuki Noda of the National Institute of Advanced Industrial Science and Technology have all served as president since Kitano's founding term, and the federation is closely affiliated with the IEEE Robotics and Automation Society and the Association for the Advancement of Artificial Intelligence.[6]
What is the 2050 grand challenge?
The headline goal of RoboCup is summarized in a single sentence first published by Kitano: "By the middle of the 21st century, a team of fully autonomous humanoid robot soccer players shall win a soccer game, complying with the official rules of FIFA, against the winner of the most recent World Cup."[1][27] The wording matters. The robots must be fully autonomous, meaning no human in the loop and no remote operator. They must be humanoid, ruling out wheeled or quadrupedal designs. The match must be played under FIFA rules on a regulation field with a regulation ball. And the opponent must be the reigning human world champion, not an amateur side.
The 2050 target was deliberately chosen as a multi-decade horizon. In 1997, when the goal was announced, the strongest robot soccer players were small wheeled platforms that could barely keep a ball in their grippers, and humanoid robots could not even walk reliably.[5] Moving from that baseline to humanoids that can outplay professional footballers requires breakthroughs in dozens of subfields, and the federation explicitly designed the goal to be difficult enough that no single laboratory could reach it alone. Progress is made by hundreds of teams working in parallel on interlocking problems and sharing their results through the annual symposium.
Progress toward 2050 is hard to summarize in a single number, but the federation tracks several intermediate milestones. By the late 2010s, adult-size humanoid robots could walk reliably, kick the ball with intent, and recover from being shoved by an opponent.[20] By the mid-2020s, kid-size and teen-size humanoids could play full matches with goalkeepers, defenders, and strikers, and some teams had demonstrated in-walk kicks where the robot strikes the ball without breaking stride.[20] Whether the 2050 deadline will be met remains an open question, but the technologies developed along the way have already had substantial impact on robotics outside the soccer pitch.
What are the major divisions and leagues?
RoboCup is organized into a hierarchy of divisions and leagues. The major divisions are RoboCupSoccer, RoboCupRescue, RoboCup@Home, RoboCup Industrial, and RoboCupJunior. Each division contains one or more leagues, each with its own rules, hardware constraints, and technical committee. The table below summarizes the leagues as they stood through the 2025 competition cycle, with the 2026 restructuring noted in the relevant rows.
| League | Division | Description |
|---|---|---|
| Small Size League (SSL) | RoboCupSoccer | Teams of eleven wheeled robots (six in the smaller Division B), each constrained to an 18 cm diameter cylinder, play with an orange golf ball on a 12 m by 9 m field (9 m by 6 m in Division B). Overhead cameras feed positions to off-field computers that run team strategy. The league emphasizes high-speed multi-agent control and ball-centric tactics. |
| Middle Size League (MSL) | RoboCupSoccer | Teams of up to five fully autonomous wheeled robots up to 80 cm tall play with a regulation FIFA size 5 ball on a 22 m by 14 m field. All sensing and decision making must happen on board. |
| Standard Platform League (SPL) | RoboCupSoccer | All teams use the same humanoid hardware (the Nao robot, made by Aldebaran and for several years by SoftBank Robotics) and compete only on software. The league took its current name after RoboCup 2007, succeeding the Sony AIBO four-legged league, and has used the Nao since 2008. Beginning in 2026 the SPL merges with the Humanoid League into the new Humanoid Soccer League. |
| Humanoid League (Kid, Teen, Adult) | RoboCupSoccer | Teams design and build their own humanoid robots in size classes: KidSize (40 to 90 cm), AdultSize (130 to 180 cm), and, until 2019, TeenSize (80 to 140 cm). The league is the most direct precursor to the 2050 challenge. From 2026 it is unified with the SPL into the Humanoid Soccer League. |
| Simulation League (2D and 3D) | RoboCupSoccer | Soccer matches are played entirely in software. The 2D league uses an abstract field with eleven point agents per side. The 3D league uses simulated humanoid bodies with full physics, originally based on the Nao model. The league tests coordination algorithms without hardware constraints. |
| Rescue Robot League | RoboCupRescue | Teleoperated and autonomous robots search for simulated victims in arenas modeled on collapsed buildings. Standard test methods developed with the U.S. National Institute of Standards and Technology evaluate mobility, mapping, and victim identification. |
| Rescue Simulation League | RoboCupRescue | Software agents represent fire trucks, ambulances, police, and civilians in a city-scale earthquake simulation. The league studies large-scale coordination and resource allocation in disaster response. |
| RoboCup@Home Open Platform | RoboCup@Home | Teams build their own service robots and run a series of household benchmarks including object manipulation, person recognition, and natural language interaction in a simulated home. |
| Domestic Standard Platform (DSPL) | RoboCup@Home | All teams use the Toyota Human Support Robot (HSR) and compete on software. The league launched at RoboCup 2017 in Nagoya. |
| Social Standard Platform (SSPL) | RoboCup@Home | All teams use the SoftBank Pepper robot. The league emphasizes social interaction, dialogue, and gesture. From 2026 it is merged with DSPL and OPL into a single unified @Home league. |
| RoboCup@Work | RoboCup Industrial | Mobile manipulators perform tasks in a simulated factory environment, including transporting workpieces between machines and reacting to dynamic orders. From 2026 it merges with the Logistics League into the new Smart Manufacturing League. |
| RoboCup Logistics League (RCLL) | RoboCup Industrial | Two teams of three Festo Robotino robots run a simulated factory floor with modular production stations. The league models in-factory logistics and Industry 4.0 challenges. |
| RoboCupJunior Soccer | RoboCupJunior | School-age students design autonomous robots for two-on-two soccer matches with an infrared ball. Categories include Lightweight and Open. |
| RoboCupJunior Rescue | RoboCupJunior | Student-built robots navigate a tiled course, identify victims, and deliver rescue kits. Categories include Line, Maze, and Simulation. |
| RoboCupJunior OnStage | RoboCupJunior | Students choreograph robot performances to music, blending engineering with creative expression. The category was formed in 2014 from the earlier Dance and Theatre tracks. |
Soccer Leagues in Detail
Small Size League
The Small Size League (SSL) is one of the two original soccer leagues that opened RoboCup-97.[3] Teams of eleven wheeled robots in the main Division A (six in Division B), each fitting inside a cylinder 18 cm in diameter and 15 cm tall, play with an orange golf ball on a 12 m by 9 m carpeted field (9 m by 6 m in Division B).[37] Overhead cameras feed pixel coordinates to a shared SSL-Vision server, and each team's off-field computer reads those coordinates and sends radio commands back to its robots fifty or more times per second. Because perception is centralized and the robots themselves are simple omnidirectional wheeled platforms, the league rewards extremely fast strategy, passing, and shooting. Modern SSL games regularly feature ball speeds above ten meters per second and intricate set-piece plays that resemble human soccer tactics in miniature.
The SSL has been a driving force for multi-agent coordination research. Teams such as CMDragons from Carnegie Mellon University, Skuba from Kasetsart University, RoboFEI from Brazil, ZJUNlict from Zhejiang University, and TIGERs Mannheim from Baden-Wurttemberg Cooperative State University have produced widely cited papers on play selection, opponent modeling, and dynamic role assignment. TIGERs Mannheim has dominated the league throughout the 2020s, winning every title from 2021 through 2026, and tops the league's Hall of Fame ranking of its most successful teams.[28]
Middle Size League
The Middle Size League (MSL) raises the difficulty by removing centralized perception. Each robot, with a footprint no larger than a 56 cm square (including its safety border) and up to 80 cm tall, must sense the ball, the field markings, the opposing robots, and its own teammates using only on-board cameras and sensors. Teams of five robots play on a 22 m by 14 m field (18 m by 12 m is allowed at local tournaments) with a regulation FIFA size 5 ball.[38] The league has historically been a showcase for omnidirectional locomotion, ball-handling devices, and decentralized team play. Tech United Eindhoven from Eindhoven University of Technology has been the dominant team for more than a decade, and at RoboCup 2024 in their home city, Tech United secured their eighth world championship by defeating Chinese team BigHeroX 6-1 in the final.[10]
Standard Platform League
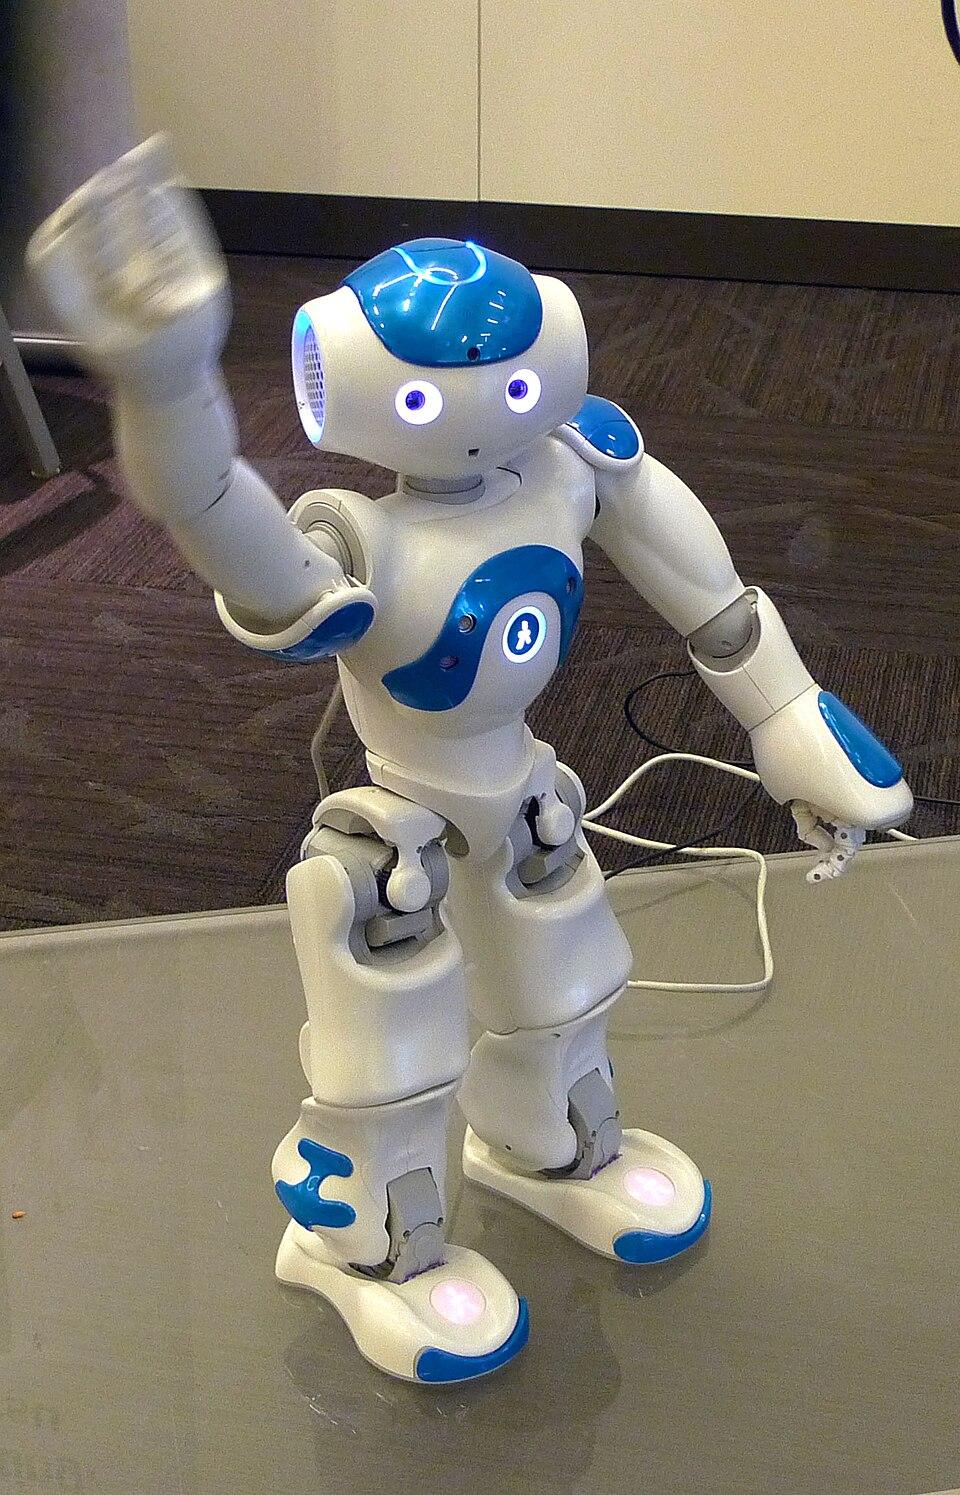
The Standard Platform League (SPL) eliminates the hardware advantage by requiring all teams to use the same robot. Since 2008 that robot has been the Nao, a 58 cm tall humanoid produced first by Aldebaran Robotics and later by SoftBank Robotics. The SPL is widely regarded as the most fertile testbed for software-only innovation in RoboCup because every team starts from the same physical platform. Vision algorithms, kinematic models, walk engines, localization filters, and team behavior frameworks are all developed in software, and the resulting code is often released open source.
The SPL is closely associated with B-Human, a joint team from the University of Bremen and the German Research Center for Artificial Intelligence (DFKI). B-Human won the world championship in 2009, 2010, 2011, 2013, 2016, 2017, 2019, 2021, 2022, 2023, 2024, and 2025, accumulating twelve world titles by the end of the 2025 season in Salvador.[9] The 2025 final was the last competition ever held in the Standard Platform League, and it was also the first time B-Human had won a RoboCup on the American continent after second-place finishes in Mexico City (2012) and Montreal (2018) and a third-place finish in Joao Pessoa (2014).[9] At that final B-Human defeated RoboEireann from Ireland, with WisTex United (University of Wisconsin-Madison and the University of Texas at Austin) finishing third.[11] B-Human also released its annual code base each year, and the team's open-source software and detailed Team Description Papers have become teaching resources used by other SPL teams worldwide. The SPL grew out of the earlier four-legged Sony AIBO league, which began in 1998 and was renamed the Standard Platform League after RoboCup 2007; the 2008 competition still ran an AIBO division alongside the Nao.[32]
Humanoid League
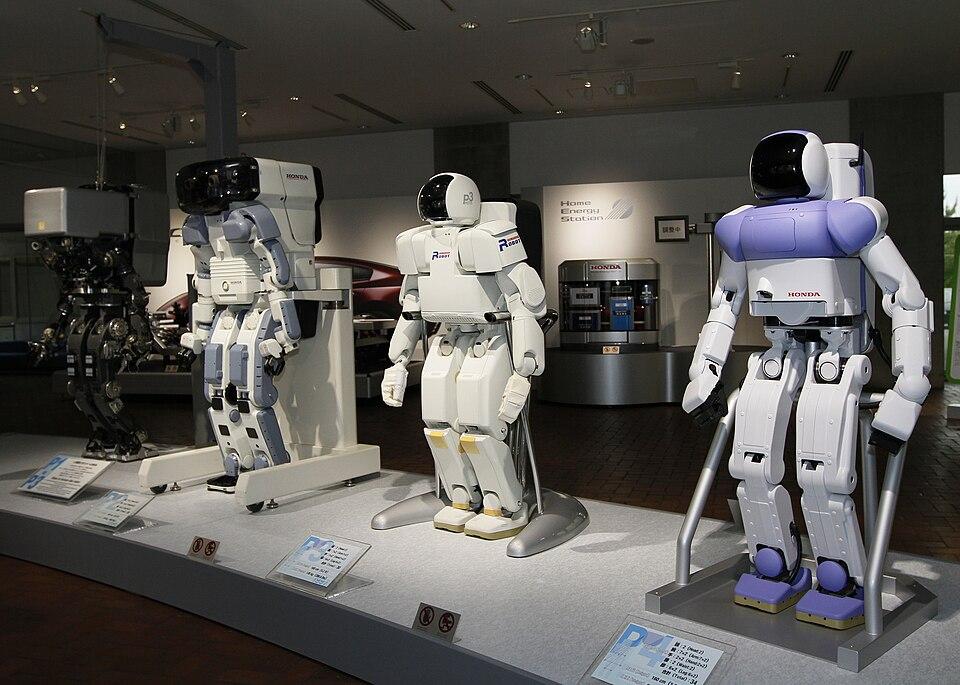
The Humanoid League is the closest analog to the 2050 goal, because every robot must be self-built and broadly humanoid in shape. The league used size classes: KidSize covered robots from about 40 to 90 cm tall and AdultSize from 130 to 180 cm, with a TeenSize class (80 to 140 cm) contested until 2019.[29] Teams design their own mechanical platforms, electronics, and software, which means the Humanoid League integrates mechatronics, control, and AI in ways the standardized SPL cannot.
NimbRo, a team from the Autonomous Intelligent Systems group at the University of Bonn, has dominated the AdultSize category since the late 2010s, winning the AdultSize world championship in 2017, 2018, 2019, 2022, and 2023, often without conceding a goal.[20] The team is known for its custom NimbRo-OP2 and NimbRo-OP2X robots, the NimbRoNet deep learning vision pipeline, and waveform-based in-walk kicks that allow the robot to strike the ball without first stopping.[20] Rhoban Football Club, based at the LaBRI laboratory of the University of Bordeaux, has been the leading KidSize team. Rhoban won the KidSize world championship in 2016, 2017, 2018, 2019, and 2023 with its custom Sigmaban robot, and at RoboCup 2019 in Sydney the team performed the first in-game throw-in in the history of the Humanoid League.[21] Beginning in 2026 the SPL and Humanoid League are unified into the Humanoid Soccer League (HSL), bringing all humanoid soccer research under a single set of rules and pushing all teams toward the larger, more capable robots that the 2050 challenge demands.[15]
Simulation League
The Simulation League runs soccer matches entirely in software, removing hardware as a variable and letting researchers focus purely on coordination algorithms. The 2D Simulation League uses an abstract field with eleven point agents per side, each receiving noisy local observations and sending discrete commands to a central simulator. The 2D league has a long history of multi-agent learning research and has been the source of widely cited base codes including HELIOS by Hidehisa Akiyama and the Fukuoka research group, WrightEagle from the Multi-Agent Systems Lab at the University of Science and Technology of China, and Cyrus2D.[18] WrightEagle, which models 2D soccer as a partially observable stochastic game and uses Monte Carlo tree search with hierarchical state abstraction, won six world championships between 2006 and 2015 and remains a reference design for online planning in adversarial multi-agent settings.[19] HELIOS won the 2D league in 2010, 2012, 2017, 2018, and every year from 2022 to 2025, and in many years has been the most copied open-source code base in the league.[18][33]
The 3D Simulation League uses simulated humanoid bodies with full rigid-body physics, allowing researchers to study locomotion and high-level behavior together without the cost of building physical hardware. The 3D simulation has often featured Nao-like models running in the SimSpark physics engine, and the league has been an early proving ground for deep reinforcement learning in soccer, including techniques later transferred to physical humanoid platforms.
RoboCupRescue
RoboCupRescue grew out of the Great Hanshin earthquake of 17 January 1995, which struck Hyogo Prefecture in Japan and killed more than six thousand people, the majority of them in Kobe.[22] The disaster exposed serious gaps in urban search and rescue, and the Japanese government responded by funding research into robotic systems that could enter unstable rubble, locate survivors, and relay information to rescuers.[22] Several of the founders of RoboCup were directly involved in that effort, and the first RoboCupRescue competition was held at RoboCup 2001 in Seattle.[4]
The Rescue division contains two leagues. The Rescue Robot League runs in physical arenas built around standardized test methods developed with the U.S. National Institute of Standards and Technology (NIST).[22] Robots, often crawler-tracked or hybrid platforms with manipulator arms and thermal cameras, navigate ramps, stair sets, debris fields, and confined spaces while searching for simulated victims that emit heat, sound, and motion. The Rescue Simulation League uses a software simulator that models a city-scale earthquake, with separate agent teams representing fire brigades, ambulance crews, police forces, and civilian populations. The simulation studies coordination, communication under duress, and resource allocation in time-critical disaster response, and has produced research that has been applied in real-world emergency planning exercises. Methods and platforms refined in the Rescue League have been deployed in real disasters including the response to the Fukushima Daiichi nuclear accident.[22]
RoboCup@Home
RoboCup@Home was created in 2006 to benchmark autonomous service robots in realistic domestic settings, and it has grown into the largest international competition for service robots.[23] Teams set up their robots in a furnished apartment arena and run a series of standardized tests including "GPSR" general-purpose service requests where the robot must understand a free-form spoken instruction, "Help Me Carry" where it follows a person and carries shopping bags, and "Restaurant" where it serves customers in an unstructured cafe layout.[16] Tests change every year and emphasize human-robot interaction, navigation in dynamic environments, object manipulation, computer vision under natural light, and dialogue.[23]
The league has three sub-divisions. The Open Platform League (OPL) lets each team design its own robot. The Domestic Standard Platform League (DSPL), launched in 2017, uses the Toyota Human Support Robot (HSR), a wheeled mobile manipulator with a single arm and lift mechanism that Toyota distributes to participating laboratories. The Social Standard Platform League (SSPL) uses the SoftBank Pepper, a wheeled humanoid with a tablet on its chest that emphasizes social interaction. At RoboCup 2024 in Eindhoven, the Japanese team Hibikino-Musashi@Home won the Domestic Standard Platform League.[10][30] Beginning at RoboCup 2026 in Incheon, the three @Home sub-leagues are unified into a single league with a shared benchmark structure, although teams may continue to bring different hardware platforms.[14]
RoboCup Industrial
RoboCup Industrial covers the @Work and Logistics leagues, which apply the RoboCup methodology to factory and warehouse problems. RoboCup@Work asks teams of mobile manipulators to perform pick-and-place and transport tasks in a simulated industrial cell, reacting to dynamic orders from a referee box. The RoboCup Logistics League (RCLL), founded in 2012 with sponsorship from the German automation company Festo, runs a simulated smart factory in which two teams of three Festo Robotino mobile robots compete simultaneously on the same field.[17] The robots fetch raw materials, route them through modular production stations equipped with RFID tags, and deliver finished goods, all while a referee box dynamically generates new orders mid-game.[17] The Robotino 3 platform has been the standard since 2015. Beginning in 2026 the @Work and Logistics leagues merge into the new Smart Manufacturing League (SML), reflecting the convergence of warehouse logistics and on-floor manufacturing in real industry.[14]
RoboCupJunior
RoboCupJunior is the federation's educational division, aimed at primary and secondary school students up to age 19. The first international Junior event was held at RoboCup 2000 in Melbourne with three categories: Dance, Sumo (later Rescue), and Soccer.[4] The current categories are Soccer, Rescue, and OnStage, the last formed in 2014 by merging the older Dance and Theatre tracks into a single creative performance category. RoboCupJunior matches use small low-cost robots, often built on Lego Mindstorms, VEX, or microcontroller kits, and the competition emphasizes student creativity, technical learning, and team collaboration. Beyond the global RoboCup event, RoboCupJunior runs a network of regional and national competitions, including a strong presence in Australia, Germany, Japan, China, and the United States. Many graduate students and professional roboticists trace their first robotics experience to RoboCupJunior.
Who are the recent world champions?
The table below lists the world champions in selected leagues from RoboCup 2019 through 2025, the last edition before the 2026 league restructuring; the @Home column gives the Domestic Standard Platform League winner.[28][29][30][31][32]
| Year | Standard Platform | Humanoid AdultSize | Humanoid KidSize | Middle Size | Small Size (Division A) | @Home DSPL |
|---|---|---|---|---|---|---|
| 2019 (Sydney) | B-Human | NimbRo | Rhoban Football Club | Tech United Eindhoven | ZJUNlict | Tech United Eindhoven |
| 2022 (Bangkok) | B-Human | NimbRo | CIT Brains | Tech United Eindhoven | TIGERs Mannheim | Tech United Eindhoven |
| 2023 (Bordeaux) | B-Human | NimbRo | Rhoban Football Club | Tech United Eindhoven | TIGERs Mannheim | Tidyboy |
| 2024 (Eindhoven) | B-Human | RoMeLa UCLA | CIT Brains | Tech United Eindhoven | TIGERs Mannheim | Hibikino-Musashi@Home |
| 2025 (Salvador) | B-Human | Tsinghua Hephaestus | Boosted HTWK | (not held) | TIGERs Mannheim | Hibikino-Musashi@Home |
Several teams stand out as long-running powerhouses. B-Human has won twelve SPL world titles by the close of the 2025 season, more than any other SPL team.[9] NimbRo won five straight Humanoid AdultSize championships from 2017 to 2023 before finishing second to RoMeLa UCLA in 2024.[20][29] Rhoban won five KidSize titles between 2016 and 2023.[21][29] Tech United Eindhoven has won the Middle Size League eight times.[10] TIGERs Mannheim has won every SSL title since 2021, including the 2025 final at Salvador and the 2026 tournament in Incheon.[28] WrightEagle from USTC won six 2D Simulation titles between 2006 and 2015, a record since passed by HELIOS, whose 2025 win was its eighth.[19][33] Hibikino-Musashi@Home from the Kyushu Institute of Technology has won the Domestic Standard Platform League four times (2017, 2018, 2024 and 2025).[30]
Where is RoboCup held each year?
RoboCup is hosted in a different city each year, with bids assessed by the federation board on the basis of facilities, sponsor support, and outreach. The table below lists the host cities of the World Championship since the founding event.
| Year | Host City | Country |
|---|---|---|
| 1997 | Nagoya | Japan |
| 1998 | Paris | France |
| 1999 | Stockholm | Sweden |
| 2000 | Melbourne | Australia |
| 2001 | Seattle | United States |
| 2002 | Fukuoka and Busan | Japan and South Korea |
| 2003 | Padua | Italy |
| 2004 | Lisbon | Portugal |
| 2005 | Osaka | Japan |
| 2006 | Bremen | Germany |
| 2007 | Atlanta | United States |
| 2008 | Suzhou | China |
| 2009 | Graz | Austria |
| 2010 | Singapore | Singapore |
| 2011 | Istanbul | Turkey |
| 2012 | Mexico City | Mexico |
| 2013 | Eindhoven | Netherlands |
| 2014 | Joao Pessoa | Brazil |
| 2015 | Hefei | China |
| 2016 | Leipzig | Germany |
| 2017 | Nagoya | Japan |
| 2018 | Montreal | Canada |
| 2019 | Sydney | Australia |
| 2020 | (cancelled, COVID-19) | n/a |
| 2021 | Online (Worldwide) | virtual event |
| 2022 | Bangkok | Thailand |
| 2023 | Bordeaux | France |
| 2024 | Eindhoven | Netherlands |
| 2025 | Salvador, Bahia | Brazil |
| 2026 | Incheon (Songdo Convensia) | South Korea |
| 2027 | Nuremberg (scheduled, 17 to 21 June) | Germany |
RoboCup 2024 in Eindhoven, hosted at the MECC convention center close to Tech United's home university, drew roughly three hundred teams from forty countries across the five major divisions.[10] RoboCup 2025 ran from 15 to 21 July 2025 at the Convention Center of Salvador in Bahia, Brazil, with more than 250 teams from 37 countries and with the major league finals concluding on 20 July and the symposium on 21 July.[12][25] The 2025 event was the first World Championship to be held on the South American mainland since 2014 and the first ever to be held in the city of Salvador.[12] RoboCup 2026 was held from 30 June to 6 July 2026 at the Songdo Convensia in Incheon, which the federation billed as the first RoboCup held in South Korea (Busan had been named co-host of RoboCup 2002 with Fukuoka); organizers expected more than 3,000 competitors and around 15,000 visitors.[13][26] On 5 July 2026, B-Human beat HTWK Robots 4:0 in what the federation called the first full 11-vs-11 soccer match between two humanoid robot teams, both playing on Booster Robotics hardware.[34] RoboCup 2027 is scheduled for 17 to 21 June 2027 at the Nuremberg Exhibition Center in Germany.[36] The 2026 edition debuted the unified Humanoid Soccer League, whose robots compete in three size divisions: Small (height under 110 cm, mass under 15 kg), Middle (under 125 cm, under 25 kg), and Large (under 190 cm, under 80 kg).[26]
In addition to the World Championship, the federation runs annual regional Open competitions including the RoboCup German Open, RoboCup Asia-Pacific, RoboCup Brazil Open, RoboCup Iran Open, RoboCup Latin America, and the RoboCup European Championship. These regional events serve both as qualifiers and as standalone scientific meetings, and they typically draw hundreds of additional teams each year.
How has RoboCup advanced AI research?
RoboCup has had broad and sustained influence on AI and robotics research, and the impact is documented through the annual RoboCup Symposium proceedings published by Springer in the Lecture Notes in Artificial Intelligence series.[24] Several research threads are particularly tied to the competition.
Probabilistic localization is one of the most cited examples. The Monte Carlo Localization (MCL) algorithm, introduced by Sebastian Thrun, Dieter Fox, Wolfram Burgard, and Frank Dellaert at the 1999 AAAI conference, was developed on office and museum tour-guide robots such as RHINO and Minerva, and RoboCup teams quickly adopted and adapted it for soccer.[8] MCL represents a robot's belief about its position as a cloud of weighted particles and updates that cloud as new sensor measurements arrive.[8] The algorithm became a standard tool in mobile robotics and is the basis for the localization stack in the popular Robot Operating System (ROS) navigation packages. The need to localize fast-moving four-legged AIBOs and later Nao robots on a soccer field, with limited compute and noisy vision, drove refinements such as Lenser and Veloso's sensor resetting localization, an idea that Thrun and colleagues cite as closely related to their Mixture-MCL algorithm.[7]
Real-time computer vision is another area where RoboCup has driven progress. Teams have to identify the ball, the field markings, the goals, opposing robots, and their teammates from on-board cameras at thirty frames per second or more, with strict latency budgets and changing lighting. Early teams developed efficient color segmentation pipelines, and more recent teams have introduced custom convolutional neural networks (NimbRoNet from the University of Bonn is a well known example) that perform full perception of ball, field, and humanoid bodies in milliseconds on the limited compute of the Nao or a teen-size humanoid.[20] RoboCup has been a useful proving ground for compact deep learning architectures suitable for embedded inference.
Multi-agent coordination and team play research has long been concentrated in RoboCup. The Simulation 2D league in particular has produced a large body of work on play recognition, opponent modeling, role assignment, and online planning, including the influential WrightEagle work that frames soccer as a partially observable stochastic game solved by Monte Carlo tree search with hierarchical decomposition.[19] The Small Size League has driven research on centralized multi-agent control with extremely tight latency budgets, while the Middle Size and Humanoid leagues have developed decentralized cooperation protocols suitable for robots with only on-board sensing and unreliable wireless communication.
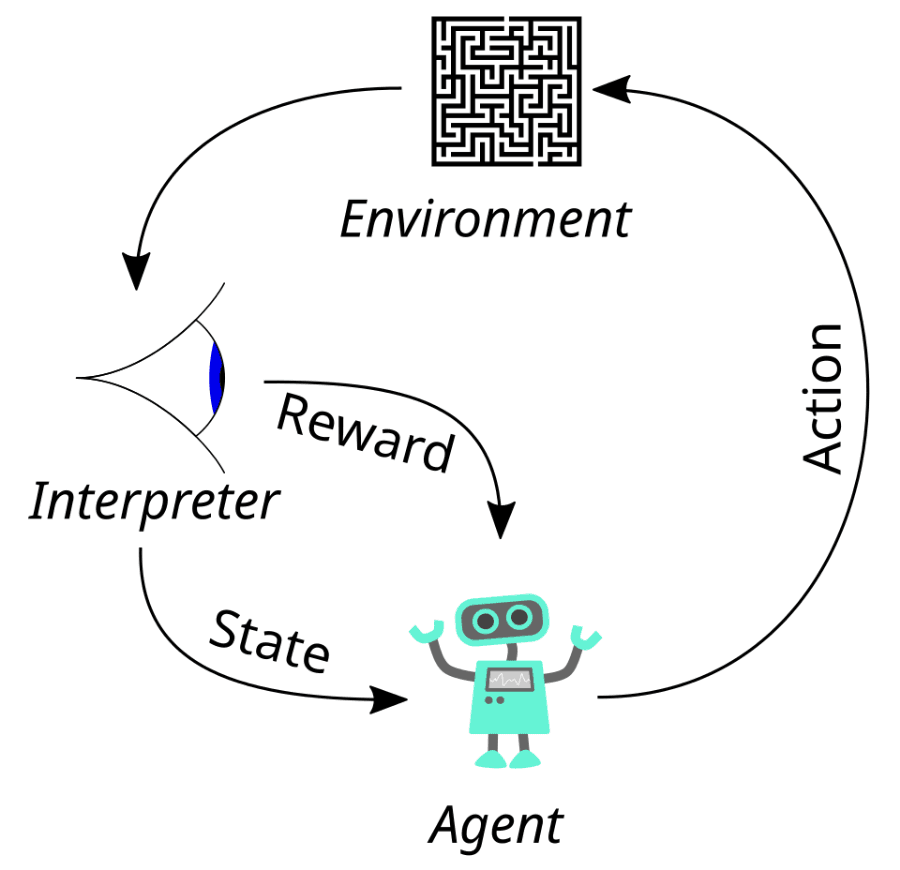
Deep reinforcement learning has become an increasingly important tool across the soccer leagues. The 3D Simulation League has hosted a series of demonstrations in which agents learn end-to-end skills, including walking, getting up after a fall, and dribbling, with policy gradients and self-play. Several of these techniques have been transferred from simulation to physical platforms in the SPL and Humanoid League, where engineers blend learned policies with classical control. In 2023 and 2024, DeepMind published research showing how soccer skills learned in simulation could be transferred to small bipedal robots, work that built on a long lineage of RoboCup research.
Beyond soccer, RoboCupRescue has shaped urban search and rescue robotics, and the test methods developed in the Rescue Robot League with NIST have been adopted by emergency response agencies around the world.[22] RoboCup@Home has driven progress in service robotics, integrating speech recognition, natural language understanding, manipulation, and navigation into single working systems.[23] The Logistics League has been a vehicle for Industry 4.0 research, demonstrating that mobile manipulator fleets can operate dynamically on a shared factory floor with no central scheduler.[17]
Notable Teams and People
A handful of teams and researchers have shaped RoboCup over its history. Hiroaki Kitano of Sony Computer Science Laboratories was the founding president and co-author of the original 1997 challenge paper.[1] Minoru Asada of Osaka University co-founded the project and led the Humanoid League for years. Manuela Veloso of Carnegie Mellon University built the long-running CMUnited and CMDragons teams, served as president of the federation, and has authored many of the most cited papers on multi-agent learning in soccer.[6] Daniele Nardi of Sapienza University of Rome served as federation president. Itsuki Noda of AIST helped invent the Soccer Simulator and has also served as president. Peter Stone of the University of Texas at Austin produced foundational work on layered learning in the Simulation League. Manuela Veloso's group, notably through Scott Lenser's sensor resetting localization for AIBO soccer robots, adapted Monte Carlo Localization to the demands of RoboCup.[7]
Key teams include B-Human (University of Bremen and DFKI) in the SPL, NimbRo (University of Bonn) in the Humanoid AdultSize, Rhoban Football Club (LaBRI, University of Bordeaux) in the Humanoid KidSize, Tech United Eindhoven in the Middle Size League, TIGERs Mannheim in the Small Size League, WrightEagle (USTC) and HELIOS (Fukuoka) in 2D Simulation, magmaOffenburg in 3D Simulation, the CMDragons and CMUnited family from Carnegie Mellon, the Hibikino-Musashi@Home team from the Kyushu Institute of Technology in the @Home league, and Carologistics (RWTH Aachen and Aachen University of Applied Sciences) in the Logistics League. Many of these teams release their code and Team Description Papers each year, creating a substantial open-source ecosystem that newcomers can build on.
Is RoboCup open source?
A defining feature of RoboCup is its commitment to open scientific exchange. Teams are required to publish a Team Description Paper (TDP) before each World Championship, in which they document their hardware, software, and scientific contributions. Many teams also release their full source code under permissive licenses. The B-Human releases for the Standard Platform League, the HELIOS and Cyrus2D base codes for the 2D Simulation League, the SSL-Vision shared vision system for the Small Size League, the SimSpark physics simulator for the 3D Simulation League, and the Federation's standardized referee boxes for the Logistics, Rescue Simulation, and SPL leagues are all freely available and have lowered the barrier for new teams to enter.[18] The annual RoboCup Symposium publishes peer-reviewed papers in the Springer Lecture Notes in Artificial Intelligence series, and the federation has formal cooperation agreements with the IEEE Robotics and Automation Society and the Association for the Advancement of Artificial Intelligence.[24]
The community also runs targeted outreach. RoboCupJunior brings tens of thousands of students into robotics each year, and many federation events include public viewing days, school tours, and engineering exhibitions. The federation maintains a code of conduct and a sustained effort to broaden participation across regions, with regional Opens in Europe, Asia-Pacific, the Americas, the Middle East, and Africa.
Future Directions
The federation used the mid-2020s to consolidate and refocus the leagues. The 2026 World Championship in Incheon debuted the unified Humanoid Soccer League, formed by merging the Standard Platform League and the Humanoid League.[15] The unification reflects a strategic decision to push every soccer team toward larger, fully self-built humanoid robots that move the project closer to the 2050 goal.[14] RoboCup@Home likewise consolidated its three sub-leagues into a single open league starting in 2026.[14][39] The @Work and Logistics leagues merged into the new Smart Manufacturing League, introduced in 2026, recognizing that the boundary between warehouse logistics and on-floor manufacturing has effectively dissolved in modern Industry 4.0 systems.[14]
The 2050 grand challenge remains the lodestar. Whether or not robots actually take the field against the human World Cup champions in 2050, the work done in pursuit of that target has already produced advances in reinforcement learning, bipedal locomotion, computer vision, multi-agent coordination, and disaster response that have shaped robotics research worldwide.[5] RoboCup continues to play the role its founders intended: a single, unifying problem against which a global community of researchers can measure their progress.[1]
Continue reading
- RoboticsRobotics is the interdisciplinary study and engineering of robots: embodied machines whose mechanisms, sensors, computation, and actuators are organized to perform tasks in the physical world.Mentioned 17 times above
- Artificial IntelligenceArtificial intelligence (AI) is the field of computer science dedicated to creating systems that perform tasks normally requiring human intelligence, such as learning, reasoning, recognizing patterns…Mentioned 9 times above
- Humanoid Robot"Humanoid" redirects here. For the London-based robotics company, see Humanoid (company).Mentioned 8 times above
- NAO (robot)NAO is an autonomous, programmable humanoid robot originally developed by Aldebaran Robotics, a French company founded in Paris in 2005 by Bruno Maisonnier.Mentioned 8 times above
- Reinforcement learningReinforcement learning (RL) is a branch of machine learning in which an agent learns to make decisions by taking actions in an environment to maximize a cumulative reward signal, discovering good behavior…Mentioned 4 times above
- Multi-agent systemA multi-agent system (MAS) is a system composed of multiple interacting intelligent agents that collaborate, compete, or negotiate to accomplish tasks that would be difficult or impossible for a single agent.Mentioned twice above
More from See also
More to read
References
- ^1 ^2 ^3 ^4 ^5 ^6 ^7Kitano, H., Asada, M., Kuniyoshi, Y., Noda, I., Osawa, E., and Matsubara, H. (1997). "RoboCup: A Challenge Problem for AI." *AI Magazine*, 18(1), 73-85. Association for the Advancement of Artificial Intelligence.
- ^Kitano, H., Asada, M., Kuniyoshi, Y., Noda, I., and Osawa, E. (1997). "RoboCup: The Robot World Cup Initiative." *Proceedings of the First International Conference on Autonomous Agents*, 340-347. ACM.
- ^1 ^2 ^3 ^4 ^5 ^6 ^7 ^8RoboCup Federation. "A Brief History of RoboCup." Official RoboCup web site, www.robocup.org/a_brief_history_of_robocup.
- ^1 ^2 ^3RoboCup Federation. "Past RoboCup events." Official RoboCup web site, www.robocup.org/past_robocup_events.
- ^1 ^2 ^3 ^4IEEE Spectrum. "RoboCup History: Robot Soccer Past and Future." IEEE Spectrum, spectrum.ieee.org/robocup-robot-soccer.
- ^1 ^2Veloso, M., and Stone, P. "A history of RoboCup with Manuela Veloso." Robohub, robohub.org.
- ^1 ^2Thrun, S., Fox, D., Burgard, W., and Dellaert, F. (2001). "Robust Monte Carlo localization for mobile robots." *Artificial Intelligence*, 128(1-2), 99-141.
- ^1 ^2Fox, D., Burgard, W., Dellaert, F., and Thrun, S. (1999). "Monte Carlo Localization: Efficient Position Estimation for Mobile Robots." *Proceedings of AAAI-99*, 343-349.
- ^1 ^2 ^3Universitaet Bremen. "Bremen Is World Champion: B-Human Wins 2025 RoboCup World Cup." University of Bremen press release, 2025, www.uni-bremen.de.
- ^1 ^2 ^3 ^4Eindhoven University of Technology. "Tech United becomes robot soccer world champion in Eindhoven." TU/e News, 21 July 2024.
- ^RoboCup Standard Platform League Technical Committee. "RoboCup 2025 SPL Winners." spl.robocup.org, July 2025.
- ^1 ^2 ^3RoboCup 2025 organizing committee. "RoboCup 2025 Salvador, Brazil." 2025.robocup.org.
- ^1 ^2RoboCup 2026 organizing committee. "RoboCup 2026 Incheon." www.robocup.org/events/80.
- ^1 ^2 ^3 ^4 ^5RoboCup Federation. "Re-Imagining RoboCup" announcement on league restructuring for 2026.
- ^1 ^2RoboCup Humanoid League Technical Committee. "RoboCup 2026 Humanoid Soccer League: Call for Participation." www.robocup.org/news/187.
- ^RoboCup@Home Technical Committee. "RoboCup@Home: Where the best domestic service robots test themselves." athome.robocup.org.
- ^1 ^2 ^3 ^4Niemueller, T., Ewert, D., Reuter, S., Ferrein, A., Jeschke, S., and Lakemeyer, G. (2014). "RoboCup Logistics League Sponsored by Festo: A Competitive Factory Automation Testbed." *RoboCup 2013: Robot World Cup XVII*, Lecture Notes in Computer Science 8371, Springer.
- ^1 ^2 ^3Akiyama, H., and Nakashima, T. (2014). "HELIOS Base: An Open Source Package for the RoboCup Soccer 2D Simulation." *RoboCup 2013: Robot World Cup XVII*, Springer LNCS 8371.
- ^1 ^2 ^3Bai, A., Wu, F., and Chen, X. (2014). "The Decision-Making Framework of WrightEagle, the RoboCup 2013 Soccer Simulation 2D League Champion Team." *RoboCup 2013*, Springer LNCS.
- ^1 ^2 ^3 ^4 ^5 ^6Pavlichenko, D., Ficht, G., Villar-Corrales, A., et al. (2024). "RoboCup 2023 Humanoid AdultSize Winner NimbRo: NimbRoNet3 Visual Perception and Responsive Gait with Waveform In-walk Kicks." *RoboCup 2023: Robot World Cup XXVI*, Springer LNAI.
- ^1 ^2Gondry, L., Hofer, L., Laborde-Zubieta, P., et al. (2019). "Rhoban Football Club: RoboCup Humanoid KidSize 2019 Champion Team Paper." *RoboCup 2019: Robot World Cup XXIII*, Springer LNAI.
- ^1 ^2 ^3 ^4 ^5 ^6Tadokoro, S., et al. "RoboCupRescue Robot League." RoboCupRescue technical reports.
- ^1 ^2 ^3 ^4Iocchi, L., Holz, D., Ruiz-del-Solar, J., Sugiura, K., and van der Zant, T. (2015). "RoboCup@Home: Analysis and Results of Evolving Competitions for Domestic and Service Robots." *Artificial Intelligence*, 229, 258-281.
- ^1 ^2 ^3RoboCup IEEE RAS Technical Committee. "RoboCup as a strategic initiative to advance technologies." IEEE Robotics and Automation Society, www.ieee-ras.org/robocup/.
- ^1 ^2 ^3RoboCup Federation. "RoboCup 2025 to showcase the world's top robot soccer teams in Brazil." Robotics and Automation News, 5 July 2025; and RoboCup Federation, "A Brief History of RoboCup" (38 teams, 11 countries at RoboCup-97).
- ^1 ^2RoboCup 2026 organizing committee and Humanoid Soccer League Technical Committee. "RoboCup 2026 Incheon: Humanoid Soccer League divisions and event scale." 2026.robocup.org and hsl.robocup.org.
- ^1 ^2RoboCup Federation. "Objective." robocup.org/objective
- ^1 ^2 ^3RoboCup Small Size League. "Hall of Fame." ssl.robocup.org/hall-of-fame
- ^1 ^2 ^3 ^4RoboCup Humanoid League. Competition results, 2016-2025. humanoid.robocup.org/...ule-and-results-rc-hl-2025
- ^1 ^2 ^3RoboCup@Home. "Awards." athome.robocup.org/awards ; and RoboCup@Home Salvador 2025 scores, github.com/...Salvador2025
- ^RoboCup Middle Size League. "Awards" and "History." msl.robocup.org/awards and msl.robocup.org/history
- ^1 ^2RoboCup Standard Platform League. "Standard Platform League History." spl.robocup.org/history
- ^1 ^2RoboCup Soccer Simulation League. "2D Soccer Simulation Awards." ssim.robocup.org/...2d-awards
- ^RoboCup Federation. "While the World Watches Soccer, Robots Made History in Incheon." 5 July 2026. robocup.org/...192
- ^ISR-Lisboa. "Pedro Lima elected President of the RoboCup Federation." 15 July 2026. isr.tecnico.ulisboa.pt/...f-the-robocup-federation
- ^RoboCup Germany. "RoboCup 2027." 2027.robocup.org
- ^RoboCup Federation. "Small Size League: Call for Participation | RoboCup 2026." 9 January 2026. robocup.org/...188
- ^RoboCup Middle Size League. "Rulebook MSL 2025, version 26.0." msl.robocup.org/...Rulebook_MSL2025_v26.0.pdf
- ^RoboCup@Home. "First Call for Participation, RoboCup@Home 2026." 7 October 2025. athome.robocup.org/...rticipation-robocuphome-2026
Improve this article
Add missing citations, update stale details, or write a clearer explanation. Anyone can edit: changes go live when you publish, and every edit is checked by an editor.
13 revisions · v13 · 6,741 words · full history
Fact-checks are independent of edits: a reviewer re-verifies the article against its sources and stamps the date. How we verify
Research and drafting on this wiki are AI-assisted, under named human editorial standards. How AI is used here
Reviewer note: Independent fact-check of the full article against its cited sources (190 claims, 48 sources fetched); 27 material + 23 minor fixed
Cite this page: AI Wiki. "RoboCup." aiwiki.ai, updated 28 Oct 2026, fact-checked 4 Nov 2026. CC BY 4.0. https://aiwiki.ai/wiki/robocup