

ALOHA 2
ALOHA 2 is an open-source, low-cost bimanual teleoperation hardware platform released in February 2024 by an Google DeepMind led team working with the original ALOHA authors at Stanford University. It is the second generation of ALOHA, an acronym for A Low-cost Open-source Hardware system for bimanual teleoperation, and it keeps the leader-follower puppeteering design while adding a redesigned low-friction gripper, passive gravity compensation, and a simplified frame to make large-scale manipulation data collection faster, more comfortable, and more reliable. ALOHA 2 is the data-collection workcell behind several high-profile robot learning efforts, including ALOHA Unleashed and the vision-language-action (VLA) model Gemini Robotics, whose training data was collected on a fleet of ALOHA 2 robots,[10] and all of its hardware designs plus a matched MuJoCo model are released openly. [1][2]
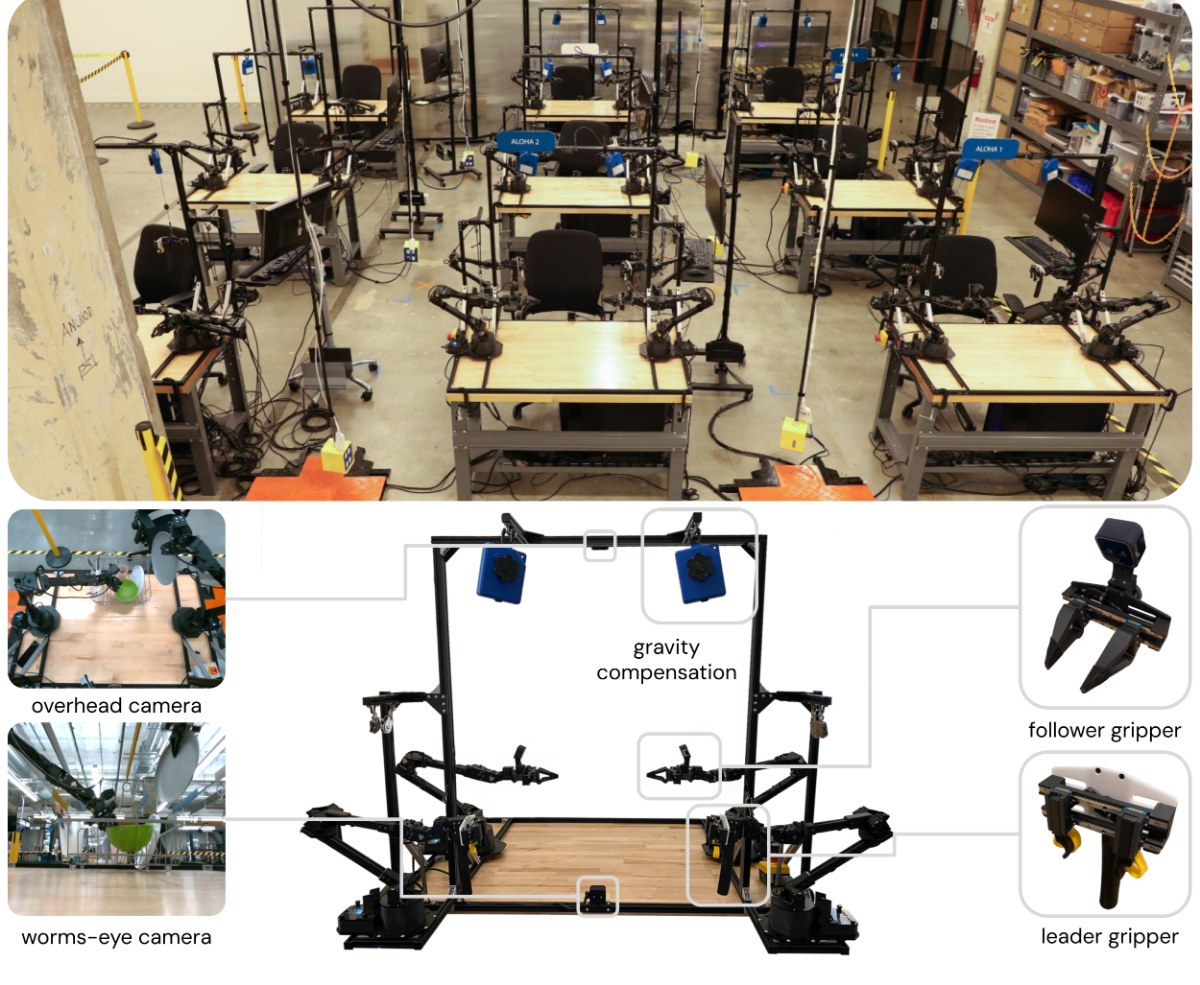
ALOHA 2 was introduced in a technical report by the "ALOHA 2 Team," a group of 25 authors that includes Tony Z. Zhao, Chelsea Finn, Pete Florence, Jonathan Tompson, Ayzaan Wahid, and Kevin Zakka. [1] The hardware, simulation models, and reference code are published on the project site aloha-2.github.io, and commercial kits were produced by Trossen Robotics (the ALOHA Stationary, Mobile and Solo kits); by late 2026 Trossen listed the ALOHA Stationary V2.0 and ALOHA Solo as discontinued, with its line rebranded as Trossen AI. [2][7] Across 2024 to 2026, ALOHA 2 has become one of the de facto reference cells for academic and industrial work on bimanual fine manipulation, in part because of its low cost and open design. [1]
What is ALOHA 2?
ALOHA 2 is a bimanual parallel-jaw teleoperation workcell built from two larger "follower" arms and two smaller "leader" arms. A human operator backdrives, or "puppeteers," the two leader arms by hand, and the two follower arms mirror that motion in real time, while the system records joint positions, gripper states, and synchronized multi-view camera streams. [1] The follower arms are 6-DoF ViperX 300 arms and the leader arms are 6-DoF WidowX 250 arms, both from Trossen Robotics and both driven by Dynamixel servos from Robotis. [1][2] The goal of the platform is to let non-experts collect high-quality demonstration data for imitation learning at a scale and cost that prior bimanual rigs could not reach.
The ALOHA 2 paper frames the problem directly: "Diverse demonstration datasets have powered significant advances in robot learning, but the dexterity and scale of such data can be limited by the hardware cost, the hardware robustness, and the ease of teleoperation. We introduce ALOHA 2, an enhanced version of ALOHA that has greater performance, ergonomics, and robustness compared to the original design." [1]
Background
Original ALOHA (2023)
The first ALOHA system was developed at Stanford University by Tony Z. Zhao, Vikash Kumar, Sergey Levine, and Chelsea Finn, and described in the 2023 paper Learning Fine-Grained Bimanual Manipulation with Low-Cost Hardware. [3] The hardware paired two ViperX 300 follower arms with two WidowX 250 leader arms, all built around Dynamixel servos from Robotis. A human operator grasped the leader arms and moved them through a task; the follower arms mirrored the motion in real time, recording joint angles and RGB video from four webcams, two of them mounted on the wrists. The system was built on a budget of about $20,000. [3]
Alongside the hardware, the Stanford team released Action Chunking with Transformers (ACT), an imitation learning algorithm that predicts short sequences of future actions rather than a single next action. ACT helped the policies learn fine-grained skills such as opening a Ziploc bag, slotting a battery, opening a translucent condiment cup, and threading a velcro cable tie from about 50 demonstrations per task. [3]
Mobile ALOHA (2024)
In January 2024, Zhao and collaborators released Mobile ALOHA, which mounted the original ALOHA arms on a wheeled AgileX Tracer base with onboard power and compute. [4] The base let the system collect demonstrations of whole-body tasks such as cooking shrimp, calling an elevator, and rinsing a pan in a sink. Mobile ALOHA used the same teleoperation principle, with the operator physically tethered to the base and backdriving its wheels while both hands control the arms. The Mobile ALOHA paper and viral demo videos drew significant attention on social media and helped trigger the wider 2024 wave of household robot learning work. [4]
How does ALOHA 2 improve on the original ALOHA?
ALOHA 2 was announced in a short technical report titled ALOHA 2: An Enhanced Low-Cost Hardware for Bimanual Teleoperation, released on arXiv (2405.02292) with a first version dated February 7, 2024, by the ALOHA 2 Team. [1] The report presents it as an enhanced version of ALOHA with greater performance, ergonomics, and robustness.
The most concrete gains are in the gripper and the operator interface. The redesigned leader gripper replaces the original scissor mechanism with a low-friction rail design and lower-gear-ratio motors (swapping the XL430-W250-T for the XC430-W150-T), which cuts the force needed to open and close the leader gripper by roughly 10 times, from about 14.68 N to about 0.84 N. [1] On the follower side, the new gripper can exert more than double the closing force of the old design, about 27.9 N versus 12.8 N, improving grasps on small or thin objects. [1] ALOHA 2 also adds passive gravity compensation using off-the-shelf adjustable hanging retractors rather than active software compensation; in a user study this passive approach let operators complete more shapes per minute (about 1.38 versus 0.97 for the software-based system). [1]
The main changes compared with the original ALOHA are summarised below. [1]
| Subsystem | Original ALOHA (2023) | ALOHA 2 (2024) | Reason given by the authors |
|---|---|---|---|
| Gripper | Original ALOHA scissor-style leader gripper; PLA and acrylic follower gripper structure | Redesigned low-friction parallel-jaw rail gripper with carbon-fiber-nylon fingers and polyurethane gripping tape | About 10x less leader force (14.68 N to 0.84 N) and more than double follower force (27.9 N vs 12.8 N); more consistent grasps on thin or deformable objects |
| Leader arm gravity compensation | Not described in the ALOHA 2 report | Passive gravity compensation via adjustable hanging retractors | Reduces operator fatigue; outperformed active compensation in a user study (1.38 vs 0.97 shapes/min) |
| Frame | Aluminium extrusion table built per lab | Simplified 20x20 mm extrusion cell with side frames removed | Repeatable setup, more workspace for human-robot collaboration and larger props |
| Cameras | Four webcams (two stationary, two on the wrists) | Four Intel RealSense D405 cameras (RGB and depth, global shutter) with new lower-profile mounts | Depth and global shutter for experimentation; lower wrist profile reduces collisions |
| Compute and timing | Joint data at 50 Hz | ROS2 software stack, still logging at 50 Hz, with session checks that shut down on missing data | Complete, high-quality data for downstream learning |
| Simulation | MuJoCo XML released after publication | MuJoCo model shipped at launch with system identification | Sim-to-real and policy debugging |
| Documentation | Build guide and BOM on GitHub | Full assembly tutorial and certified vendor kit through Trossen Robotics | Lower barrier for new labs |
The MuJoCo model is calibrated through system identification on 11 real trajectories, tuning proportional gain, damping, armature, joint friction, and torque limits so that the simulator matches the physical arms. [1]
What is ALOHA 2 used for?
ALOHA 2 became the data collection backbone for a string of high-profile robot learning papers in 2024 and 2025.
ALOHA Unleashed, released by Google DeepMind in October 2024, used 10 ALOHA 2 cells to gather what the authors describe as data at a scale previously unmatched by any bimanual platform: over 26,000 demonstrations across 5 real-world tasks, plus more than 2,000 demonstrations on 3 simulated tasks. [5] The tasks included dexterous, contact-rich skills such as tying shoelaces, hanging a shirt on a hanger, replacing a robot finger, and inserting plastic gears onto a socket. The policies were trained with a diffusion policy head on top of a transformer trunk, and the paper argues that the combination of large-scale ALOHA 2 data collection and expressive diffusion models is a "simple recipe" for learning challenging bimanual manipulation involving deformable objects. [5]
The Octo generalist policy from Berkeley was also evaluated on ALOHA-style bimanual tasks, although Octo was trained primarily on the Open X-Embodiment corpus rather than on ALOHA 2 data alone.
Outside Google, Physical Intelligence included data from bimanual and mobile Trossen (ALOHA-type) robots among the 8 robot platforms used to train its π0 generalist policy. [6]
The combination of low cost, open hardware, and a growing body of pre-trained checkpoints means that a researcher can buy or build an ALOHA 2 cell, plug in a published policy, and reproduce headline tasks within days rather than months.
Which labs use ALOHA 2?
ALOHA 2 is used by academic and industrial groups beyond the original Stanford and DeepMind teams. The project page directs buyers to Trossen Robotics kits, and ALOHA-type hardware has been used beyond Google DeepMind, for example in Physical Intelligence's π0 training data. [2][6]
The Hugging Face LeRobot library hosts ALOHA datasets and implements policies such as ACT and diffusion policies that are commonly trained on them. [8]
How does ALOHA 2 compare to other teleoperation platforms?
ALOHA 2 sits in a distinct part of the design space from the industrial dual-arm cells that preceded it. The table below compares it with several commonly cited alternatives. ALOHA and Mobile ALOHA costs come from their papers; the Franka and UR5e figures are rough estimates rather than reported prices. [3][4]
| Platform | Year | Arms | Teleop method | Approximate hardware cost | Openness |
|---|---|---|---|---|---|
| ALOHA 2 | 2024 | 2 x ViperX 300 6-DoF followers, 2 x WidowX 250 6-DoF leaders | Kinematically matched leader-follower puppeteering | Not stated in the paper; Trossen kit discontinued by 2026 | Open hardware, open software |
| Original ALOHA | 2023 | Same arms, earlier revision | Puppeteering | Around $20,000 | Open hardware, open software |
| Mobile ALOHA | 2024 | ALOHA arms on a mobile base | Puppeteering plus driven base | Around $32,000 | Open hardware, open software |
| Franka Emika Panda dual-arm rig | 2018 onward | 2 x Franka Panda | VR controllers, haptic phantom, or kinesthetic teaching | Roughly $60,000 to $120,000 depending on setup | Proprietary hardware, ROS drivers |
| Universal Robots UR5e dual-arm cell | Varies | 2 x UR5e | VR controllers, scripting, or kinesthetic | Roughly $80,000 to $150,000 | Proprietary hardware, open APIs |
| Tesla Optimus or Figure data collection rigs | 2024 to 2025 | Humanoid full-body | Motion capture suits or VR | Not publicly priced | Closed |
The ALOHA family trades absolute precision and payload for cost and openness. Franka and UR5 cells offer sub-millimetre repeatability and force-torque sensing out of the box, which matters for industrial tasks. ALOHA 2 relies on hobby-grade Dynamixel servos that are noticeably less stiff, but the puppeteering interface lets non-experts collect data with very little training, which is the bottleneck for imitation learning at scale. [1]
Is ALOHA 2 open source?
Yes. The ALOHA 2 paper states that the team open sources all hardware designs of ALOHA 2 with a detailed tutorial, together with a MuJoCo model of ALOHA 2 with system identification. [1] The hardware bill of materials, CAD, assembly instructions, and software stack are published on the project site, and the simulation model is distributed through MuJoCo Menagerie. [2] Because the designs are open and the parts are off-the-shelf, third parties such as Trossen Robotics sell pre-assembled kits, and the Hugging Face LeRobot library distributes drivers and reference policies. [7][8]
Continue reading
- ALOHA (robot system)ALOHA (A Low-cost Open-source Hardware System for Bimanual Teleoperation) is an open-source robotic platform for collecting bimanual manipulation demonstrations and training imitation learning policies, built…Mentioned 66 times above
- Mobile ALOHAMobile ALOHA is an open-source, low-cost system for collecting bimanual mobile manipulation data and learning household tasks from it, developed at Stanford University by Zipeng Fu, Tony Z. ZhaoMentioned 6 times above
- Robot learningRobot learning studies how robots acquire or improve behavior from data and experience.Mentioned 4 times above
- Imitation LearningImitation learning is a family of methods for learning sequential behavior from demonstrations.Mentioned 3 times above
- Google DeepMindGoogle DeepMind is an artificial intelligence research and model-development organization at Google.Mentioned 3 times above
- Stanford UniversityStanford University, legally Leland Stanford Junior University, is a private, nonprofit research university in Stanford, California.Mentioned twice above
More from See also
References
- ^1 ^2 ^3 ^4 ^5 ^6 ^7 ^8 ^9 ^10 ^11 ^12 ^13 ^14ALOHA 2 Team, Google DeepMind. *ALOHA 2: An Enhanced Low-Cost Hardware for Bimanual Teleoperation*. arXiv:2405.02292, first version 7 February 2024. <arxiv.org/...2405.02292>
- ^1 ^2 ^3 ^4 ^5ALOHA 2 project page. <aloha-2.github.io>
- ^1 ^2 ^3 ^4Zhao, T. Z., Kumar, V., Levine, S., Finn, C. *Learning Fine-Grained Bimanual Manipulation with Low-Cost Hardware*. Robotics: Science and Systems, 2023. <tonyzhaozh.github.io/aloha>
- ^1 ^2 ^3Fu, Z., Zhao, T. Z., Finn, C. *Mobile ALOHA: Learning Bimanual Mobile Manipulation with Low-Cost Whole-Body Teleoperation*. CoRL 2024 / arXiv:2401.02117. <mobile-aloha.github.io>
- ^1 ^2Zhao, T. Z., Tompson, J., Driess, D., Florence, P., Ghasemipour, K., Finn, C., Wahid, A. (Google DeepMind). *ALOHA Unleashed: A Simple Recipe for Robot Dexterity*. CoRL 2024 / arXiv:2410.13126. <aloha-unleashed.github.io>
- ^1 ^2Physical Intelligence. *π0: A Vision-Language-Action Flow Model for General Robot Control*. 2024. <physicalintelligence.company/...pi0>
- ^1 ^2Trossen Robotics, ALOHA 2 / ALOHA Stationary product page. <trossenrobotics.com/aloha-stationary>
- ^1 ^2Hugging Face LeRobot, ALOHA 2 examples. <github.com/...lerobot>
- Open X-Embodiment Collaboration. *Open X-Embodiment: Robotic Learning Datasets and RT-X Models*. ICRA 2024. <arxiv.org/...2310.08864>
- ^Gemini Robotics Team, Google DeepMind. *Gemini Robotics: Bringing AI into the Physical World*. arXiv:2503.20020, March 2025. <arxiv.org/...2503.20020>
Improve this article
Add missing citations, update stale details, or write a clearer explanation. Anyone can edit: changes go live when you publish, and every edit is checked by an editor.
7 revisions · v7 · 2,189 words · full history
Fact-checks are independent of edits: a reviewer re-verifies the article against its sources and stamps the date. How we verify
Research and drafting on this wiki are AI-assisted, under named human editorial standards. How AI is used here
Reviewer note: Independent fact-check of the full article against its cited sources (85 claims, 17 sources fetched); 9 material + 18 minor fixed
Cite this page: AI Wiki. "ALOHA 2." aiwiki.ai, updated 28 Oct 2026, fact-checked 5 Nov 2026. CC BY 4.0. https://aiwiki.ai/wiki/aloha_2