

Genesis AI (company)
Genesis AI is a robotics company building a general-purpose robot foundation model, the dexterous hardware the model runs on, and the simulation software used to develop it. At its 2025 launch it described itself as a "physical AI" research lab and full-stack robotics company; its 2026 announcements call it "a global full-stack robotics company."[4][5] Genesis AI was founded in December 2024 by Zhou Xian, who holds a robotics PhD from Carnegie Mellon University, and Théophile Gervet, a machine-learning PhD from the same school and a former research scientist at the French AI lab Mistral.[1] It emerged from stealth on July 1, 2025 with a $105 million seed round co-led by Eclipse Ventures and Khosla Ventures.[1] It launched with offices in Paris and Palo Alto, California; its 2026 press releases carry Paris and San Carlos, California datelines, and by May 2026 it had also opened an office in London.[7][5][33]
In May 2026 Genesis AI unveiled its first model, GENE-26.5, together with a human-scale dexterous robotic hand and a tactile data-collection glove. Later that month it released Genesis World 1.0, a simulation platform that it said it uses mainly to evaluate its models, and in June it introduced Eno, its first announced general-purpose robot.[2][5][27][20] In July 2026, Bloomberg reported that the company was in talks to raise around $500 million at a $3 billion pre-money valuation, with Premji Invest in talks to lead. The report described ongoing negotiations, not a completed financing.[17][25] In October 2026 Nvidia announced a planned investment in the company; the size was not disclosed.[23][24]
The company shares a name and a founder with the open-source Genesis physics engine (now called Genesis World), an academic project that Zhou Xian helped lead. The two are related but distinct, and the relationship is explained in the Relationship to the open-source Genesis engine section below.
Overview
Genesis AI's central thesis is that progress in robotics is bottlenecked by data. Large language models could be trained on trillions of tokens scraped from the internet, but there is no comparable corpus of physical-interaction data for robots, and collecting it on real hardware is slow and expensive. At its 2025 launch, Genesis AI's answer was a "data-centric, full-stack" pipeline that combines high-fidelity physics simulation, multimodal generative modeling, and large-scale real-robot data collection into a single data engine, with its in-house simulation stack meant to "generate rich synthetic data at scale" alongside real-world data.[4]
The emphasis shifted over the following year. By May 2026 the company described human demonstration data as its main source for pretraining: data captured with a tactile glove that maps onto its robotic hand, egocentric video from people wearing cameras, and internet video of human activity.[5][14] In a May 2026 technical post it said that, in the short term, real-world data collection had "turned out to be economically viable" at the scale it needed, and that it was using simulation chiefly as an evaluation engine, without relying on any synthetic data from simulation in pretraining at that stage.[27]
The company frames the opportunity in macroeconomic terms. Its launch materials said physical labor contributes an estimated $30 trillion to $40 trillion to global GDP and that more than 95 percent of it remains unautomated, and CEO Zhou Xian stated that "general-purpose robots powered by physical AI will define the next major chapter of human history."[4] Reuters reported in May 2026 that the company was targeting sectors such as automotive, electronics, pharmaceuticals, and logistics, where conventional robots struggle with delicate or variable tasks.[32]
History
Founding
Genesis AI was founded in December 2024 by Zhou Xian and Théophile Gervet, who both completed PhDs at Carnegie Mellon University advised by Katerina Fragkiadaki.[1][10][36] The French commercial register lists Genesis AI SAS as an active company, created on December 23, 2024 and registered with the Paris RCS under SIREN 938 912 912, with Zhou as president and Gervet as director general.[19] Zhou Xian, the chief executive, studied at Nanyang Technological University in Singapore before completing a PhD at CMU's Robotics Institute, where his publications included work on generative simulation, differentiable physics, and robot learning, such as RoboGen, Gen2Sim, DiffTactile, and ThinShellLab.[36] Gervet, who serves as president, completed a machine-learning PhD at CMU, working on computer vision and 3D robot manipulation, with papers such as Act3D and contributions to embodied-navigation work.[10] He also took a couple of years of leave to build the machine-learning product and team at Relyance AI. In November 2023 he joined Mistral AI as a research scientist working on open-source models; his site lists the releases of Mixtral 8x7B and Pixtral 12B among his work there.[10] Sifted, which reported on the company before its public launch, referred to it as Genesis Robotics.[9]
The two founders had worked together before the company. Gervet and Zhou co-authored Act3D (CoRL 2023), a manipulation-policy transformer that uses 3D feature fields for multi-task robot manipulation, with Nikolaos Gkanatsios and Fragkiadaki.[38] Zhou's earlier research included FluidLab (2023), a differentiable environment for benchmarking complex fluid manipulation, and RoboGen (ICML 2024), a "generative robotic agent" that uses foundation and generative models to propose tasks, scenes, and training supervision in simulation so that robot skills can be learned at scale.[39][40][36]
A July 2025 profile by the Chinese venture outlet Investment World, republished by 36Kr, traced the company's origins to 2022, when Zhou interned at the MIT-IBM Watson AI Lab, worked with Chuang Gan, and met researchers who later joined him. It described a founding team of about 20 people, many drawn from the academic Genesis project, and named Zhenjia Xu (previously in charge of real-robot systems on Nvidia's GEAR team), Tsun-Hsuan Wang (rendered in the translation as Wang Zunxuan; an MIT PhD advised by Daniela Rus who had worked as a research scientist at Liquid AI), and Yiling Qiao (a University of Maryland PhD) among its founding members.[35] Wang's own page describes him as a PhD student at MIT CSAIL advised by Rus and a part-time researcher at Liquid AI, and he is a co-author of RoboGen.[41][39] The company's own announcements name only Zhou and Gervet as co-founders.[5][29]
According to the company, it was founded by academic and industry researchers from Mistral AI, Nvidia, Google, CMU, MIT, Stanford, Columbia, and the University of Maryland.[4] TechCrunch reported at launch that several participants in the academic Genesis project had joined the company, making up a staff of more than 20 researchers who specialized in robotics, machine learning, and graphics.[1]
Funding
Genesis AI operated in stealth for roughly six months before its public launch. An earlier report by Sifted in June 2025 described an $85 million close;[9] the company's formal stealth exit on July 1, 2025 announced a $105 million seed round.[1][7][8] Reuters described it as one of the largest seed rounds raised in France, matching the record seed raised by Mistral AI.[32]
| Round | Date | Amount | Lead investors | Other participants |
|---|---|---|---|---|
| Seed | July 1, 2025 | $105 million | Eclipse Ventures, Khosla Ventures | Bpifrance, HSG (HongShan Capital Group; formerly Sequoia China), Eric Schmidt, Xavier Niel, Daniela Rus, Vladlen Koltun[2][3][18] |
| Proposed financing (not closed) | Reported July 23, 2026 | About $500 million | Premji Invest reported to be in talks to lead | Talks at a reported $3 billion pre-money valuation; amounts could change[17][25] |
| Strategic investment | Announced October 12, 2026 | Not disclosed | Nvidia | Announced as a planned investment; Genesis AI called Nvidia "a strategic investor"[23][24] |
The seed round combined U.S. and Chinese venture backers at a time when much of the industry was divided along geopolitical lines.[3] HSG, also known as HongShan Capital Group, is the firm formerly known as Sequoia Capital China; HSG and HongShan are not separate investors.[18] Other backers included the French public investment bank Bpifrance and individuals including former Google chief executive Eric Schmidt, French telecom entrepreneur Xavier Niel, MIT roboticist Daniela Rus, and computer-vision researcher Vladlen Koltun.[2][5]
On July 23, 2026, Bloomberg reported, citing people familiar with the efforts, that Genesis AI was in talks with investors to raise around $500 million at a $3 billion pre-money valuation. Bloomberg said negotiations were ongoing and the amounts could change.[17] Rebecca Torrence, one of the Bloomberg reporters on the story, wrote the same day that Premji Invest was in talks to lead the round.[25] The Next Web, summarizing the reporting a day later, said HSG and Northzone were weighing further investment, that none of the firms had commented, and that Genesis AI had not confirmed the raise.[26] As of late October 2026, Genesis AI had not announced a closing; its news page listed no announcement after June 16, 2026, and its 2026 press releases described the $105 million seed as its funding.[22][31] The proposed financing is therefore not included in the company's completed funding total, and no closing date, post-money valuation, or final terms were verified in the available sources.
On October 12, 2026, Nvidia announced planned investments in four startups in France, Doctolib, Entalpic, Genesis AI and Pigment, as part of a series of European announcements before its GTC Berlin conference.[23] The next day Genesis AI confirmed an earlier Les Echos report, saying in a statement: "We are excited that Nvidia is a strategic investor in Genesis AI."[24] Neither Nvidia's announcement nor Reuters' report gave the size of the investment or said whether it was connected to the financing talks reported in July.[23][24]
Growth and GENE-26.5 launch
In March 2026 Genesis AI hired Vivian Sun, formerly head of automated driving at Amazon and chief commercial officer of Waabi, as vice president of commercial and strategy to lead commercialization, go-to-market work, and partnerships.[29] By May 2026 the company employed roughly 60 people, split about 40 to 45 percent in Europe and 50 to 55 percent in the United States, with offices in Paris, California, and a newly added presence in London.[2] On May 6, 2026 Genesis AI revealed that it had gone "full stack," developing not just software but also its own dexterous robot hand and data-collection hardware, and it launched its first foundation model, GENE-26.5.[2][15] The launch was accompanied by demonstration videos of a pair of human-scale robotic hands performing manipulation tasks. Reuters reported that the company was in advanced talks with potential customers in France, Germany, and Italy, and that the company said GENE-26.5 could run on a range of robots, including those built by other companies. Reuters placed the launch in competition with China's Linkerbot, another developer of dexterous robotic hands.[32]
Later in May the company added senior hires ahead of its first robot reveal. On May 21 it named Damien Kieran, previously chief legal and privacy officer at Tools for Humanity and chief privacy officer and deputy general counsel at Twitter (now X), as head of legal, and Pally Kumar, previously director of manufacturing at the robotics company Cobot with earlier roles at Tesla, Amazon, and Lyft, as head of operations, overseeing data collection and manufacturing.[30] On May 27 it appointed Guillaume Soulé, formerly director of operations and business development for France and Italy at Palantir, as head of European business.[31] The same day it published a technical post introducing Genesis World 1.0, its simulation platform.[27]
On June 16, 2026, Genesis AI introduced Eno, a wheeled general-purpose robot with an adjustable articulated body, two arms, and the company's dexterous hands. Genesis said it planned to begin production and targeted customer deployments by the end of 2026, starting with industrial uses; these were plans rather than completed deployments.[20] The same day, Genesis AI announced a multi-phase partnership with LG CNS to evaluate manufacturing and logistics uses, develop a rollout plan, and then conduct a pilot. The announcement did not say that the pilot or a customer deployment had already occurred.[21]
Leadership
| Name | Role | Background stated by the company | Announced |
|---|---|---|---|
| Zhou Xian | Co-founder and CEO | Robotics PhD, Carnegie Mellon University | Founder[1] |
| Théophile Gervet | Co-founder and President | Machine-learning PhD, Carnegie Mellon University; former research scientist at Mistral AI | Founder[1][5] |
| Vivian Sun | Vice President of Commercial and Strategy | Former head of automated driving at Amazon; former chief commercial officer at Waabi; early executive at TuSimple | March 11, 2026[29] |
| Damien Kieran | Head of Legal | Former chief legal and privacy officer at Tools for Humanity; former general counsel at BeReal; former chief privacy officer and deputy general counsel at Twitter (now X) | May 21, 2026[30] |
| Pally Kumar | Head of Operations | Former director of manufacturing at Cobot; earlier roles at Tesla, Amazon, and Lyft | May 21, 2026[30] |
| Guillaume Soulé | Head of European Business | Former director of operations and business development for France and Italy at Palantir | May 27, 2026[31] |
Products and technology
GENE foundation model
GENE is Genesis AI's family of robot foundation models. The first release, GENE-26.5, was announced on May 6, 2026 and described by the company as the first "AI brain" to give robots human-level physical manipulation.[5][16] The company said it named the release GENE-26.5 because it was released in May 2026, and that it expected continuous updates across the GENE family; TechCrunch likewise reported that the version is named for May 2026 and that Zhou expected many iterations.[14][2]
The model is designed to be general purpose, controlling different robot hardware across varied environments rather than being tuned to a single platform. Genesis AI's technical post describes a single model that learns a joint distribution over trajectories using flow matching, trained on heterogeneous and partially observed data: egocentric streams, glove data with tactile signals, robot control data, and internet language and video data. The company said that it had collected more than 200,000 hours of data across these modalities in collaboration with partners, and that for most of the demonstrated skills GENE required less than one hour of task-specific robot data.[14]
In launch demonstrations, robots driven by GENE-26.5 were shown:[5][6]
- preparing a 20-step meal, including cracking eggs, slicing tomatoes, and coordinating both hands;
- making and serving a smoothie, including pouring, blending, and mid-air serving;
- solving a Rubik's Cube with continuous in-air manipulation;
- playing a piano;
- performing laboratory tasks such as pipetting and liquid transfer;
- wire harnessing; and
- grasping and sorting four objects simultaneously.
The technical post adds detail on how the demonstrations were produced. All tasks ran at 1x real-world speed with a single model using shared weights, except piano playing, which used a separately trained policy learned with reinforcement learning in simulation and guided by human demonstrations, to test the control stack.[14] For the Rubik's Cube, an external solver generated commands on the fly, which were translated into language instructions for the model to execute; the company said that, to its knowledge, this was the first time a general-purpose bimanual robotic system had solved a Rubik's Cube.[14] These were company-produced demonstrations rather than independent evaluations.
The company also replaced the arm supplier's controller on its bimanual robot arms with its own control middleware. It said the system runs at 500 Hz over EtherCAT, achieves end-to-end latency as low as 3 milliseconds under tuned settings, and reduced average tracking error on a circle-tracing test from about 20 millimeters with the default controller to about 2 millimeters. Genesis AI argued that lower latency and tracking error let the model learn from human motion rather than only from robot-specific teleoperation signals.[14]
Dexterous hand and data glove
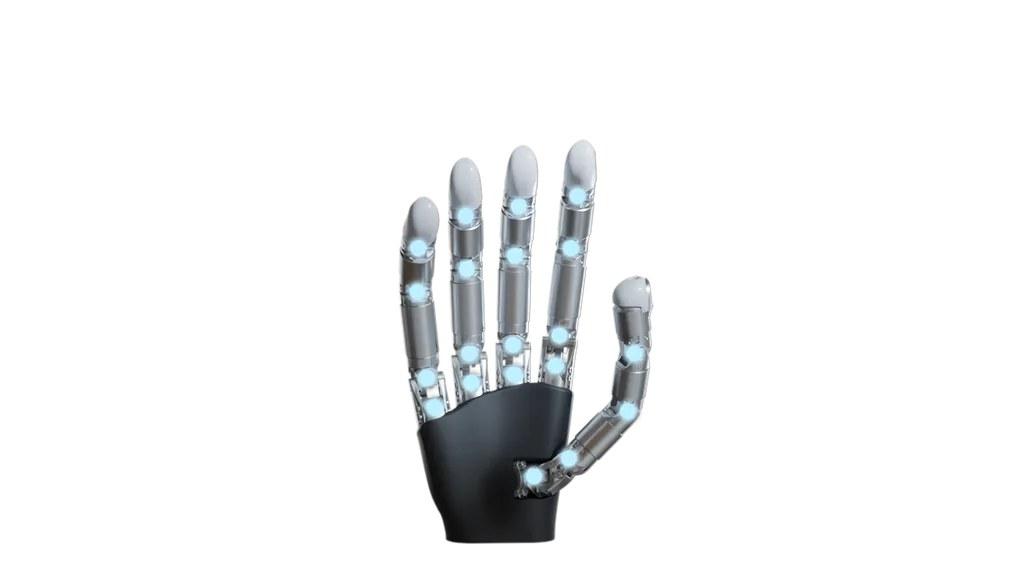
A core part of Genesis AI's full-stack approach is hardware built specifically to gather manipulation data. The company developed a proprietary end effector, a robotic hand that mirrors the human hand in form and function, replacing the simple two-finger grippers common in industrial robot manipulation.[2][5] Its technical post describes the Genesis Hand 1.0 as a direct-drive hand with a 1:1 size match to the human hand, 20 active, back-drivable degrees of freedom, and soft material over the palm and fingers to mimic the contact physics of human skin. The same post said GENE-26.5 "currently runs on a hardware platform that is already highly dexterous" and called Genesis Hand 1.0 "the next step in our hardware roadmap."[14]
The company also built a sensor-equipped data-collection glove fitted with tactile-sensing electronic skin, which it says uses EMF-based finger tracking and dense tactile sensing across the hand.[5][14] The glove is designed to create a "1:1:1 mapping" between the human hand, the glove, and the robotic hand, so that movements demonstrated by a person transfer directly to the robot without the embodiment gap that complicates other robot teleoperation setups.[5]
Gervet told TechCrunch that the glove is as light and easy to wear as the security gloves already used in many industries.[2] The company says the glove's hardware cost is about 100 times lower than typical options and that in internal testing it showed up to five times greater data-collection efficiency than traditional teleoperation.[5] TechCrunch reported that the hands shown in the launch demonstration were designed in partnership with the Chinese company Wuji Tech.[2] Humanoids Daily later reported that Wuji Tech, in a revised statement, described itself as a manufacturing collaborator for the Genesis Hand 1.0, built to Genesis AI's 1:1 human-proportion and back-drivable design requirements, rather than the supplier of an off-the-shelf Wuji Hand.[34] Humanoids Daily identified the hands in the GENE-26.5 demonstrations as the Genesis Hand 1.0, while Genesis AI's own technical post presented Hand 1.0 as the next step beyond the hardware platform the model currently runs on.[34][14] Genesis AI later fitted its proprietary hands to Eno, its first announced general-purpose robot.[20]
Data engine and simulation
GENE-26.5 is trained through a data engine that fuses three sources: data captured with the dexterous glove, egocentric video from humans wearing cameras, and human-activity videos from the internet.[14] Reuters reported that the company was working with partners to build robotics datasets, including real-world data collected from tens of thousands of industrial workers wearing sensor-equipped gloves.[32] The founders acknowledged to TechCrunch that customers might decide not to share such data with the company. Gervet suggested that whether workers would be paid for wearing the gloves was a matter between Genesis AI's customers and their employees, adding, "We haven't nailed the details yet."[2]
Genesis AI's simulation work traces back to the open-source Genesis engine, whose launch announcement claimed simulation speeds of roughly 430,000 times faster than real time.[12][13] In May 2026 the company released Genesis World 1.0, which it describes as the foundation of its simulation infrastructure. It has three main components: Nyx, a real-time path-traced renderer built for robotics; the Genesis World physics platform, which unifies rigid and deformable simulation and adds an External Articulation Constraint for incremental potential contact (IPC) and a barrier-free elastodynamics solver; and Quadrants, a compiler that turns Python kernel code into GPU-accelerated code.[27] Quadrants is published on GitHub under the Apache 2.0 license, and Nyx is distributed as a plugin for Genesis World, with its documentation and examples in a public repository.[28][42]
The company said it treats simulation as "the evaluation and iteration engine" for its foundation models rather than merely as a data generator. In a study of three models on 14 tasks with 200 episodes per task, it reported a Pearson correlation of 0.8996 between success rates in simulation and on real hardware, and it said a typical evaluation pass that would take more than 200 hours on one real robot station runs in under half an hour in simulation.[27] The company said future work would scale reinforcement-learning post-training in simulated environments and combine its classical simulator with learned world models.[27] Zhou told TechCrunch that evaluation was "the real bottleneck for the iteration speed of the model."[2] Narrowing the sim-to-real gap through matched rendering, robot dynamics, and control was a stated goal of the work.[27]
Relationship to the open-source Genesis engine
The Genesis AI company should not be confused with, but is closely connected to, the open-source Genesis physics engine (the GitHub project Genesis-Embodied-AI/genesis-world, see Genesis (simulator)). Genesis was released in December 2024 as an academic research project. Zhou Xian's announcement described it as the product of a 24-month collaboration involving more than 20 research labs, while TechCrunch later described contributors from 18 universities.[13][1] Zhou Xian, later Genesis AI's CEO, was a lead organizer of that collaboration while a PhD student at Carnegie Mellon.[1]
The open-source Genesis is a universal, GPU-accelerated simulation platform written in Python that unifies multiple physics solvers (rigid body, MPM, SPH, FEM, PBD, and others) so it can simulate rigid and articulated bodies, cloth, liquids, smoke, deformables, and more in a single scene.[11] Its launch announcement said it ran 10 to 80 times faster than existing GPU-accelerated stacks such as Nvidia's Isaac Gym and MuJoCo's MJX, reached simulation speeds around 430,000 times faster than real time, and could train a transferable robot locomotion policy in about 26 seconds on a single RTX 4090 GPU.[13] Those figures drew criticism: robotics researcher Stone Tao, who works on the ManiSkill simulator, published an analysis in December 2024 arguing that the benchmark used fast solver settings, disabled self-collisions, and left the robot idle for most of the test, and that corrected code ran about 150 times slower than the headline number. He later added a note that the Genesis team had made some fixes and published its own report, while saying that some of his points still held.[37] The project also described an upper-level generative framework meant to create 4D physical worlds and many kinds of training data automatically, with access to that framework to be rolled out gradually.[13] Genesis is distributed under the permissive Apache 2.0 license.[11]
The two entities are linked through their shared founder and technical heritage. The repository's current README says the project "was previously named Genesis," started as an academic project in December 2024, and that its development "is now officially supported by Genesis AI."[11] Genesis AI's May 2026 post describes Genesis World 1.0 as an expansion of that initial version.[27] In practice, the open-source engine is a public simulation platform for the robotics and robot learning community, while Genesis AI is a venture-funded company building proprietary foundation models, hardware, and a commercial data engine; at launch it said it planned to open-source components of its data engine and foundation model.[4] The relative-speed and "high-fidelity physics" claims most often attributed to Genesis AI originate from the open-source engine's published numbers.
Disambiguation
The name "Genesis" is heavily reused, and Genesis AI (the robotics company) is unrelated to several other things that share the word:
- Genesis the open-source physics engine described above, which is a software project rather than a company (though the two share a founder).
- Genesis, the luxury vehicle marque of Hyundai Motor Group, which has no connection to robotics foundation models.
- Various unrelated products and projects that use "Genesis" as a generic codename or brand across the technology industry.
When this article and most technology press refer to "Genesis AI," they mean the robotics startup co-founded by Zhou Xian and Théophile Gervet.
Competition
Genesis AI competes in a crowded and well-capitalized field of companies building general-purpose "brains" for robots, an area sometimes called physical AI or embodied AI. At its July 2025 launch, TechCrunch compared it with Physical Intelligence, which had raised a $400 million round, and Skild AI, which had been valued at $4 billion earlier that year.[1] In its May 2026 hardware launch, Reuters set it against Linkerbot, a Chinese maker of dexterous hands.[32] Genesis AI's emphasis on owning the full stack, from a custom physics simulator and data engine to a dexterous hand and the foundation model itself, distinguishes its approach from peers that focus primarily on the learning model or on humanoid robot hardware; with Eno it chose a wheeled design rather than a bipedal humanoid.[20] The broader category also includes simulation-and-data efforts from large incumbents, such as Nvidia Cosmos and the Isaac Lab robot-learning framework, and research programs on large behavior models for manipulation. A Khosla Ventures partner, Kanu Gulati, framed the core bet bluntly at launch, asking whether anyone would build a large robotics foundation model that truly generalizes across tasks.[1]
Continue reading
- Genesis (simulator)Genesis is an open-source, generative physics simulation platform for robotics and embodied AI, announced on December 18, 2024 (UTCMentioned 72 times above
- Dexterous handA dexterous hand (also called a dexterous robotic hand or multi-fingered robot hand) is an anthropomorphic end effector that reproduces the grasping, in-hand manipulation, and tactile perception of the human…Mentioned 4 times above
- Physical AIPhysical AI is a contested umbrella term for artificial intelligence systems whose decisions are coupled to sensing and action in the physical world.Mentioned 3 times above
- Robot foundation modelA robot foundation model is a large-scale machine learning model, typically based on the transformer architecture, that is pre-trained on broad, diverse datasets of robot interactions and then adapted to a…Mentioned twice above
- Robot learningRobot learning studies how robots acquire or improve behavior from data and experience.Mentioned twice above
- Wuji HandThe Wuji Hand is a five-finger dexterous hand developed by Wuji Tech, a Chinese robotics company that grew out of the Shanghai motor maker Pan Motor.Listed in See also
More from See also
More to read
References
- ^1 ^2 ^3 ^4 ^5 ^6 ^7 ^8 ^9 ^10 ^11"Genesis AI launches with $105M seed funding from Eclipse, Khosla to build AI models for robots." TechCrunch, July 1, 2025. techcrunch.com/...la-to-build-ai-models-for-robots
- ^1 ^2 ^3 ^4 ^5 ^6 ^7 ^8 ^9 ^10 ^11"Khosla-backed robotics startup Genesis AI has gone full stack, demo shows." TechCrunch, May 6, 2026. techcrunch.com/...i-has-gone-full-stack-demo-shows
- ^1 ^2"Robotics Startup Raises $105 Million Seed From US, China VCs." Bloomberg, July 1, 2025. bloomberg.com/...n-seed-round-from-khosla-hongshan
- ^1 ^2 ^3 ^4 ^5"Genesis AI Emerges From Stealth with $105M to Build Universal Robotics Foundation Model and Horizontal Platform for General-Purpose Physical AI." PR Newswire, July 1, 2025. prnewswire.com/...al-purpose-physical-ai-302495016
- ^1 ^2 ^3 ^4 ^5 ^6 ^7 ^8 ^9 ^10 ^11 ^12 ^13"Genesis AI Unveils GENE-26.5, the First AI Brain to Enable Robots with Human-Level Physical Manipulation Capabilities." PR Newswire, May 6, 2026. prnewswire.com/...ipulation-capabilities-302763638
- ^"Genesis AI introduces GENE-26.5 model for more dexterous robot manipulation." The Robot Report, May 6, 2026. therobotreport.com/...-more-dexterous-manipulation
- ^1 ^2"Genesis AI brings in $105M to build universal robotics foundation model." The Robot Report, July 1, 2025. therobotreport.com/...al-robotics-foundation-model
- ^"Genesis AI emerges from stealth with $105M seed funding to build robotics foundation model." Tech Funding News, July 2025. techfundingnews.com/genesis-ai-105m-seed-funding
- ^1 ^2"Exclusive: Ex-Mistral employee closes $85m round for AI and robotics startup." Sifted, June 27, 2025. sifted.eu/...exclusive-genesis-robotics-85m-round
- ^1 ^2 ^3"Theophile Gervet." Personal website, accessed October 27, 2026. theophilegervet.github.io
- ^1 ^2 ^3"Genesis-Embodied-AI/genesis-world (Simulation platform for general-purpose robotics & embodied AI learning)." GitHub, accessed October 27, 2026. github.com/...genesis-world
- ^"New physics engine lets robots practice tasks 430,000x faster." Interesting Engineering, December 2024. interestingengineering.com/...ystem-robot-training
- ^1 ^2 ^3 ^4"Announcing the Genesis project (generative physics engine, 24-month collaboration involving over 20 research labs)." Zhou Xian on X, December 18, 2024. x.com/...1869511650782658846
- ^1 ^2 ^3 ^4 ^5 ^6 ^7 ^8 ^9 ^10"GENE-26.5: Advancing Robotic Manipulation to Human Level." Genesis AI blog, May 2026. genesis.ai/...-robotic-manipulation-to-human-level
- ^"Genesis AI unveils robot brain and human-like hand to reshape industrial automation in Europe." Tech Startups, May 6, 2026. techstartups.com/...ndustrial-automation-in-europe
- ^"Genesis AI introduces GENE-26.5 robotic model." Engineering.com, May 2026. engineering.com/...roduces-gene-26-5-robotic-model
- ^1 ^2 ^3"Robotics Startup Genesis in Talks to Raise About $500 Million." Bloomberg, July 23, 2026. bloomberg.com/...-talks-to-raise-about-500-million
- ^1 ^2"About Us." HSG, accessed July 25, 2026. hsgcap.com/about-us
- ^"GENESIS AI (SIREN 938 912 912)." Pappers, registry data from INSEE, INPI, and BODACC, accessed October 27, 2026. pappers.fr/...genesis-ai-938912912
- ^1 ^2 ^3 ^4"Meet Eno." Genesis AI, June 16, 2026. genesis.ai/...meet-eno
- ^"Partnering with LG CNS to Scale General-Purpose Robotics Across Enterprise Operations." Genesis AI, June 16, 2026. genesis.ai/...partnering-with-lg-cns
- ^"News." Genesis AI, accessed October 27, 2026. genesis.ai/press
- ^1 ^2 ^3 ^4Nat Ives. "NVIDIA Announces New Investments in France's Startups." NVIDIA Blog, October 12, 2026. blogs.nvidia.com/...ce-ecosystem-agentic-computing
- ^1 ^2 ^3 ^4Inti Landauro and Leo Marchandon. "Nvidia buys stakes in French tech startups Doctolib, Genesis AI." Reuters (via The Star), October 13, 2026. thestar.com.my/...-tech-startups-les-echos-reports
- ^1 ^2 ^3Rebecca Torrence (Bloomberg). "Robotics funding scoop! Genesis AI is discussing a raise of ~$500 million at a $3 billion pre-money valuation..." Post on X, July 23, 2026. x.com/...2080435303232221656
- ^Cristian Dina. "Genesis AI is in talks to raise about $500m for its robot brains." The Next Web, July 24, 2026. thenextweb.com/...-raise-robotics-foundation-model
- ^1 ^2 ^3 ^4 ^5 ^6 ^7 ^8"The role of simulation in scalable robotics, Genesis World 1.0, and the path forward." Genesis AI blog, May 27, 2026. genesis.ai/...enesis-world-10-and-the-path-forward
- ^"Genesis-Embodied-AI/quadrants (High-performance multi-platform compiler for physics simulation)." GitHub, accessed October 27, 2026. github.com/...quadrants
- ^1 ^2 ^3"Genesis AI hires former Amazon leader Vivian Sun to advance commercialization." Genesis AI, March 11, 2026. genesis.ai/...ian-sun-to-advance-commercialization
- ^1 ^2 ^3"Genesis AI expands executive team across legal and operations with former X and Tesla leaders." Genesis AI, May 21, 2026. genesis.ai/...ions-with-former-x-and-tesla-leaders
- ^1 ^2 ^3"Genesis AI strengthens its leadership team to accelerate its growth in Europe." Genesis AI, May 27, 2026. genesis.ai/...m-to-accelerate-its-growth-in-europe
- ^1 ^2 ^3 ^4 ^5"Startup francesa apresenta modelo de IA com mão robótica semelhante à humana" (Portuguese translation of a Reuters report). IstoÉ Dinheiro with Reuters, May 6, 2026. istoedinheiro.com.br/...-modelo-de-ia-mao-robotica
- ^Matthew Broersma. "France's Genesis AI Debuts First Model, Shows Robotic Hand." Silicon UK, May 7, 2026. silicon.co.uk/...genesis-ai-robot-629791
- ^1 ^2"Wuji Tech Confirmed as Hardware Partner for Genesis AI's Human-Level Dexterity Breakthrough." Humanoids Daily, May 7, 2026 (updated). humanoidsdaily.com/...level-dexterity-breakthrough
- ^Wang Lu (Investment World). "A person born in the 1990s raised 700 million yuan in financing." 36Kr, July 3, 2025. eu.36kr.com/...3363026023581446
- ^1 ^2 ^3"Zhou Xian." Personal website, accessed October 27, 2026. zhou-xian.com
- ^Stone Tao. "How fast is the new hyped Genesis simulator?" Substack, December 20, 2024 (later updated). stoneztao.substack.com/...ped-genesis-simulator-is
- ^Theophile Gervet, Zhou Xian, Nikolaos Gkanatsios, and Katerina Fragkiadaki. "Act3D: 3D Feature Field Transformers for Multi-Task Robotic Manipulation." arXiv:2306.17817, June 2023. arxiv.org/...2306.17817
- ^1 ^2Yufei Wang, Zhou Xian, Feng Chen, Tsun-Hsuan Wang, Yian Wang, Katerina Fragkiadaki, Zackory Erickson, David Held, and Chuang Gan. "RoboGen: Towards Unleashing Infinite Data for Automated Robot Learning via Generative Simulation." arXiv:2311.01455, November 2023. arxiv.org/...2311.01455
- ^Zhou Xian, Bo Zhu, Zhenjia Xu, Hsiao-Yu Tung, Antonio Torralba, Katerina Fragkiadaki, and Chuang Gan. "FluidLab: A Differentiable Environment for Benchmarking Complex Fluid Manipulation." arXiv:2303.02346, March 2023. arxiv.org/...2303.02346
- ^"Tsun-Hsuan Wang." Personal website, accessed October 27, 2026. zswang666.github.io
- ^"Genesis-Embodied-AI/genesis-nyx (Nyx renderer plugin for Genesis world physics simulation engine)." GitHub, accessed October 27, 2026. github.com/...genesis-nyx
Improve this article
Add missing citations, update stale details, or write a clearer explanation. Anyone can edit: changes go live when you publish, and every edit is checked by an editor.
8 revisions · v8 · 4,891 words · full history
Fact-checks are independent of edits: a reviewer re-verifies the article against its sources and stamps the date. How we verify
Research and drafting on this wiki are AI-assisted, under named human editorial standards. How AI is used here
Reviewer note: Founding, seed round, reported 2026 funding talks, the Nvidia investment, leadership hires, and the GENE-26.5, Genesis Hand 1.0 and Genesis World 1.0 details were checked against company announcements and technical posts, the French company register, and TechCrunch, Reuters and Bloomberg coverage, October 2026.
Cite this page: AI Wiki. "Genesis AI (company)." aiwiki.ai, updated 28 Oct 2026, fact-checked 27 Oct 2026. CC BY 4.0. https://aiwiki.ai/wiki/genesis_ai