

openpilot
openpilot is an open-source driver-assistance system developed by comma.ai and its user community. Installed on a comma device that plugs into a supported car, it performs adaptive cruise control (ACC) and automated lane centering (ALC), and it adds lane change assist and camera-based driver monitoring.[9][7] comma's safety documentation describes it as a Level 2 driver-assistance system that requires the driver to stay alert and ready to take over at all times, not an autonomous driving system.[7] The code is published on GitHub under the MIT License, with a README warning that it is "alpha quality software for research purposes only".[3]
openpilot is notable for how much of its driving behavior is learned rather than hand-coded. Its driving model plans directly from camera images, and since 0.10 (August 2025) comma has supervised that model with a world model learned from fleet video, and since 0.11 (March 2026) it has trained the model entirely inside that learned driving simulator.[16][19] The project's README describes openpilot as "an operating system for robotics" and says: "Currently, it upgrades the driver assistance system in 300+ supported cars." The autogenerated supported-cars list carried 335 entries as of 30 October 2026.[3][8] The most recent release, 0.11.2 (23 October 2026), introduced "chestnut-class" driving models that run on an external desktop GPU, a world model with about 4 billion parameters, and reinforcement learning post-training.[1][2]
| Attribute | Value |
|---|---|
| Developer | comma.ai and community contributors[3] |
| Initial release | 0.1, dated 29 November 2016 in the release notes[5] |
| Latest release | 0.11.2 (23 October 2026)[1][6] |
| License | MIT (some components under other licenses)[3] |
| Primary language | Python (GitHub classification)[4] |
| Repository | github.com/commaai/openpilot (created 24 November 2016)[4] |
| Current hardware | comma four; comma 3X branches still maintained; optional chestnut external GPU[3] |
| Supported cars | 335 entries in the supported-cars list (as of 30 October 2026)[8] |
| GitHub stars / forks | 64,019 / 11,368 (as of 30 October 2026)[4] |
History
Origins and the comma one (2016)
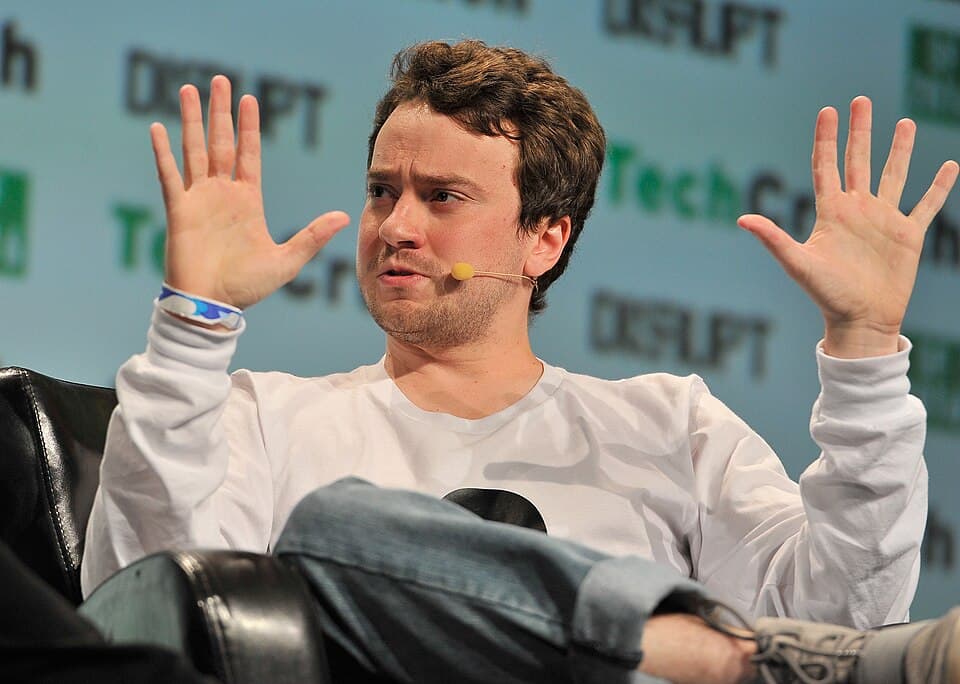
comma.ai, founded by George Hotz, unveiled the comma one, a $999 aftermarket add-on, at TechCrunch Disrupt San Francisco in September 2016.[11][10] In October 2016 the National Highway Traffic Safety Administration (NHTSA) sent the company a letter and a "special order" requiring detailed answers to 15 questions about the device's design, testing, target vehicles and sales plans.[11] NHTSA chief counsel Paul A. Hemmersbaugh wrote: "We strongly encourage you to delay selling or deploying your product on the public roadways unless and until you can ensure it is safe."[10] Hotz responded on the company's Twitter account by cancelling the comma one rather than answering.[11]
Open-source release (November 2016)
About a month later, comma.ai released its driving software for free on GitHub together with plans for a phone-based hardware unit called the Comma Neo. At a press event on 30 November 2016, Hotz called the software "Open Pilot" and framed it as an "open source alternative to [Tesla's] Autopilot". The first version worked only on specific Honda and Acura cars and required a OnePlus 3 phone running a custom operating system.[10] Hotz told reporters: "We're not shipping a product. We're shipping alpha software really for research purposes only. We do not provide any guarantees." He also said the company went open source partly to sidestep NHTSA and the California DMV, arguing that "NHTSA only regulates physical products that are sold".[10] The project's release notes date version 0.1 to 29 November 2016, with ACC and lane keep assist on the 2016 Acura ILX (with AcuraWatch Plus) and the 2016 Honda Civic Touring.[5]
Hardware generations
openpilot has run on a series of comma devices. The release notes record EON deprecation in 0.8.1 (December 2020), comma two support in 0.7.1 (January 2020), comma three support in 0.8.7 (July 2021), comma 3X support in 0.9.4 (July 2023) and comma four support in 0.10.2 (November 2025).[5] The comma 3X launched at $1,250 with a Snapdragon 845, a 6-inch OLED display and an integrated "red panda" STM32H7 microcontroller that supports CAN FD.[23] The comma four, launched at COMMA_CON 2025 for $999, packs the same compute, sensors and functions as the comma 3X into a body one-fifth the size.[24] With 0.10 (August 2025) the comma three moved to its own long-term-support release branch.[16] As of 30 October 2026 the README lists the comma four as the supported device and maintains separate release branches for the comma 3X.[3]
Toward end-to-end driving (2019 to 2024)
Early openpilot relied heavily on what comma calls "classical perception", detecting lane lines and lead cars, to make driving decisions. comma's stated goal was a fully "end-to-end" planner that imitates human driving.[12] Version 0.8.3 (April 2021) shipped a lateral-planning model trained fully end-to-end. comma's write-up described an EfficientNet-B2 vision block feeding a GRU-based policy, a "warp" simulator that synthesizes off-path views from real video, and a KL-divergence information bottleneck that stops the model from "cheating" on simulator artifacts.[12] End-to-end lateral planning was first offered behind a toggle and later became the default.[13] Release 0.8.15 (July 2022) made path planning use end-to-end output instead of lane lines at all times.[5]
openpilot 0.9.0 (November 2022) introduced "Experimental mode", in which end-to-end longitudinal planning lets the model choose speed: it slows for turns, stops at traffic lights and stop signs, and goes on green. The model was trained in a "depth reprojection" simulator with a Gaussian-channel bottleneck of about 700 bits per frame, and training from scratch took 36 hours instead of about a week.[13] comma's companion post to its 2025 paper says the reprojective-simulation approach shipped for lateral planning in 0.8.15 and for longitudinal planning in 0.9.0.[27] Release 0.9.8 (March 2025) moved the whole model runtime to tinygrad on the comma 3X, replacing a stack that began with Qualcomm's SNPE and comma's own "thneed" accelerator.[14]
World-model training (2025 to 2026)
comma traces the idea of a learned driving simulator to its 2016 paper "Learning a Driving Simulator" by Eder Santana and George Hotz.[19][25] In April 2025 nine comma authors posted "Learning to Drive from a World Model" (arXiv:2504.19077), which comma describes as a CVPR 2025 paper. It trains driving policies on-policy in two kinds of simulator, a reprojective one and a learned world model.[26][16] The paper reports deploying both policies in openpilot and calls this, to the authors' knowledge, "the first use of a world model simulator for on-policy training of a policy that is deployed in the real world".[26]
openpilot 0.10 (August 2025) shipped that architecture. The hand-tuned model-predictive control (MPC) systems were removed from training and inference for lateral control in both modes and for longitudinal control in Experimental mode. The policy was instead supervised by a world model that knows future states.[16] Version 0.10.1 (October 2025) dropped global localization inputs from the world model and doubled it from 500 million to 1 billion parameters, trained on a new list of about 2.24 million unique segments.[17] With 0.11 (March 2026), comma said that, "to the best of our knowledge", it was shipping "the first real-world robotics agent shipped to real users that was fully trained in a learned simulation": both the simulated video and the plans came from the world model. In that release the world model was a 2-billion-parameter diffusion transformer trained on 2.5 million minutes of driving video.[19]
Release timeline
| Version | Date | Highlights |
|---|---|---|
| 0.1 | 29 Nov 2016 | Initial release; ACC and lane keep assist on 2016 Acura ILX and Honda Civic[5] |
| 0.6 | Jul 2019 | New model "with double the pixels and ten times the temporal context"; panda safety code MISRA compliant[5] |
| 0.7.1 | Jan 2020 | comma two support; "supercombo" model combines calibration and driving models[5] |
| 0.8.3 | Apr 2021 | Lateral planning model trained fully end-to-end[12][5] |
| 0.8.7 | Jul 2021 | comma three support[5] |
| 0.8.15 | Jul 2022 | Path planning uses end-to-end output instead of lane lines at all times[5] |
| 0.9.0 | Nov 2022 | Experimental mode with end-to-end longitudinal control[13] |
| 0.9.4 | Jul 2023 | comma 3X support; navigate on openpilot in Experimental mode[5] |
| 0.9.8 | Mar 2025 | Model runtime moved fully to tinygrad[14] |
| 0.9.9 | Jun 2025 | Tesla Model 3 and Y support; external USB GPU groundwork[5][15] |
| 0.10.0 | Aug 2025 | World-model planner replaces MPC[16] |
| 0.10.1 | Oct 2025 | 1B-parameter world model; new UI built on raylib[17] |
| 0.10.2 | Nov 2025 | comma four support[5] |
| 0.10.3 | Dec 2025 | New temporal policy architecture; driver-monitoring model trained on data including comma four[18] |
| 0.11.0 | Mar 2026 | Driving model fully trained in a learned simulator; comma four standby power cut 77% to 52 mW[19] |
| 0.11.1 | Jun 2026 | Driver-monitoring model trained with labels from a locally hosted vision-language model[20] |
| 0.11.2 | 23 Oct 2026 | chestnut-class model on external GPU; 4B world model; RL post-training; VW ID.4 and CUPRA Born[1] |
Dates come from comma's release blog posts where one exists and otherwise from RELEASES.md. GitHub release pages and RELEASES.md sometimes differ from each other by days or weeks.[5][6]
openpilot 0.11.2
comma announced 0.11.2 on 23 October 2026 with the tagline "A better openpilot, across the board".[1][2]
chestnut-class driving model
0.11.2 is the first release with "chestnut-class" driving models, which run on an external GPU instead of the comma device's phone-class processor. The release post says the new model has "about 15x as many parameters as the small model in 0.11.1, and uses about 55x as much computation". Its parameter table lists 382.9 million parameters and 93.5 GFLOPs for the new model, against 26.6 million parameters and 1.7 GFLOPs for 0.11.1.[1] The vision backbone changed from FastViT (fastvit_t12) to ConvNeXt (convnext_xl). comma chose ConvNeXt after a backbone search based on ImageNetV2 matched-frequency results, and it initializes the encoder from pretrained weights before fine-tuning on driving data. Training segments for the vision backbone rose from 500,000 to 2.5 million.[1]
comma's sources give different size figures for this model line. The August 2026 chestnut announcement promised a "1B parameter driving model" with "30x more parameters, 100x more FLOPs" than the latest on-device model.[21] The GitHub release notes for v0.11.2 say "Big model with 880M parameters".[6] The 0.11.2 blog table gives the 382.9 million figure above.[1] None of these sources explains the difference.
Two smaller changes went into training. The "desire" labeling stack now uses offline map data and a simpler lane-change detector, which comma says improved recall for turns, exits and complex lane changes.[1] Full frames from both road cameras are now copied over USB to the chestnut, where image transformation and model inference run. comma says this prepares the input pipeline for full-frame driving models.[1] comma also said ONNX versions of the models would be published on Hugging Face. The commaai/openpilot_driving_models repository exists under an MIT license and holds files such as big_driving_supercombo.onnx.[1][33]
4B-parameter world model
The world model that supervises training grew to about 4 billion parameters. The post lists the configuration change as 56 layers, 36 heads and a 2,304-wide embedding (from 34, 20 and 1,280), with training segments rising from 2.5 million to 10 million.[1] Those "from" values match the 1-billion-parameter configuration introduced in 0.10.1, not the 2-billion-parameter model (48 layers, 25 heads, 1,600-wide embedding) described in the 0.11 post.[17][19] comma fit a scaling law "similar to Kaplan et al. 2020", L = 12.65 * F^-0.063, from smaller experiments. It says the fit was made before the full run and "predicted a loss very close to the achieved loss".[1] (See scaling laws.)
Reinforcement-learning post-training
Earlier models learned to imitate the action the world model suggested at each simulation step. The 0.11.2 policy is instead trained with an RL objective to maximize cumulative reward over an episode, so it can depart from the world model's reference when that pays off later.[1] At each step the reward compares the car's achieved lateral and longitudinal acceleration with the accelerations the world model predicted one step earlier. Smoothness terms in the actor loss penalize abrupt steering and acceleration changes.[1] The method uses the residual approach from ResFiT: a frozen pre-trained base policy plus a residual temporal policy whose tanh-squashed correction is added to the base action. The training algorithm builds on TD3, and each critic learns from a five-step return.[1]
chestnut external GPU
chestnut is a PCIe-to-USB bridge that connects a desktop GPU to a comma four. comma says it "closes the compute gap to Tesla".[1] It has a PCIe x16 slot wired with four lanes, a USB3 or USB4 host link, and a 12 V GPU power stage. On the comma four it connects over USB3 through the AUX port and draws power through an XT60 connector from the car's cigarette-lighter socket or a standard ATX supply.[1] The board is built around the ASM2464PD USB4-to-PCIe chip, running comma's own reverse-engineered firmware for the chip's 8051 core. comma reports 700 MB/s transfers over a 10 Gbit/s USB3 link.[1]
comma launched chestnut on 12 August 2026 with a "ready to drive" kit that included an AMD Radeon RX 9060 8 GB GPU. At launch the kit cost $799 and the GPU-less "tiny chestnut" $249. comma said a comma four paired with chestnut "has similar compute to Tesla HW4".[21] On 30 October 2026 the comma shop listed the ready-to-drive kit at $899 and the dock alone at $249.[22] openpilot provides separate chestnut installer branches (release-chestnut, nightly-chestnut and others).[3] The groundwork came earlier: 0.9.9 (June 2025) used tinygrad's USB GPU driver to let a desktop GPU attach to a comma 3X's auxiliary USB-C port, ahead of separate "on-device and external GPU" model classes.[15]
Driver monitoring
comma found that in 0.11.1 training, comma four driver-camera frames had been rectified with an incorrectly scaled distortion matrix. This shrank and shifted labeled faces, so some were discarded as back-seat passengers. The bug affected about 1.6% of comma four frames (about 0.32% of all training frames) and accounted for about 75% of undetected faces, causing false alerts when drivers leaned back.[1] Citing recommendations in UN Regulation No. 171, the release also reworked alert escalation. It removed the 3-second text-only alert, gave the first audible alert at 5 seconds a softer new sound, and changed lockouts to start at 1 minute instead of lasting until the ignition restarts. Repeated lockouts grow to 5, 15 and then 30 minutes.[1]
Volkswagen ID.4 as a "gold car"
comma defines a "gold car" as one whose controls are accurate enough that "every driving failure is a model failure". Before this release only the Tesla Model 3 and Model Y qualified.[1] 0.11.2 adds the Volkswagen ID.4 (2021 to 2025) and the CUPRA Born (2021 to 2023), both credited in the release notes to the contributor DaHansi (the blog post also credits lukasloetkolben for the harness and jyoung8607 for the ID.4 port). The ID.4 is comma's first car on Volkswagen's MEB platform.[1][2] In comma's lateral 0.5 Hz sine test at 30 mph, the ID.4 reached the 50% threshold in 350 ms against 423 ms for a Tesla Model Y. On that basis comma's announcement says the ID.4 "has better lateral response than the Tesla Model Y".[1][2] The MEB steering rack takes a target curvature rather than torque. comma therefore reworked its curvature safety limits to work in acceleration space, which also smooths lateral jerk on curvature-controlled Ford models.[1] comma says support for other MEB vehicles (ID.3, ID.5, ID.7, Skoda Enyaq and Elroq, CUPRA Tavascan, Audi Q4 e-tron) "will follow".[1] In Experimental mode the cruise acceleration limits were simplified so that openpilot "can accelerate as much as the model wants".[1]
comma connect, comma body and sounds
The comma connect web app gained live streaming of the road and driver cameras while the car is parked (this requires an internet connection and comma power). It can also cut clips from any part of a drive and re-encode them from the device's HEVC segments into MP4 (H.264).[1][2] The same stack enables remote teleoperation of the comma body v1 robot from connect.[1] A new family of alert sounds was designed for the comma four's speaker.[1]
Architecture
Driving model and simulator training
The driving model takes images from the road-facing cameras and outputs a plan; vehicle-specific code then turns the plan into steering, gas and brake commands sent over the car's CAN network.[9][12] Since 0.11 the training recipe has two steps: a large world model is trained on unlabeled fleet video, and a much smaller driving policy is trained on its own interactions with that world model.[19] In 0.11 the world model compressed two camera views into a latent space with a ViT encoder (50 million parameters) and decoder (100 million parameters). A block-causal diffusion transformer, trained with rectified flow and sampled with classifier-free guidance, generated future frames and plans from 2 seconds of past context and 1 second of future conditioning.[19] comma argues that a learned simulator avoids the "cheating" that hand-coded simulators invite, as long as the policy is smaller than the simulator.[19] During simulated rollouts the policy is exposed to lateral and longitudinal noise (lag, steering, pitch, gas and brake) so that it holds up on real cars.[19]
Model runtime
On the comma device, models run on the Snapdragon 845's GPU through tinygrad. comma moved both the driving and driver-monitoring models to tinygrad, away from Qualcomm's SNPE runtime.[14] chestnut-class models run on the attached desktop GPU instead.[1]
Driver monitoring
A separate neural network watches the driver through the cabin-facing camera and escalates alerts when it detects distraction.[7][1] In 0.11.1 comma trained the driver-monitoring model's phone-use labels with a locally hosted vision-language model answering a yes/no question, replacing a classifier trained on hand-labeled images. comma reported fewer false positives as a result.[20]
Safety model
openpilot's SAFETY.md sets two top-level requirements. The driver must always be able to retake control immediately by braking or pressing cancel, and the vehicle must not change its trajectory too quickly for the driver to react. For lateral limits, comma cites ISO 11270 and ISO 15622, which it translates to "0.9 seconds of maximum actuation to achieve a 1m lateral deviation".[7] comma says openpilot is "developed in good faith to be compliant with FMVSS requirements" and that it observes ISO 26262 guidelines and applies MISRA C:2012 coding rules to safety-relevant code.[7] These are comma's own statements of practice, not third-party certifications. The safety limits are enforced in C firmware on the panda microcontroller, using vehicle-specific safety code from the opendbc repository. That code is checked with cppcheck and a MISRA C:2012 add-on, unit tests for each supported car, mutation tests, and enforced 100% line coverage of the safety unit tests.[34] SAFETY.md also sets rules for forks. A fork that changes the safety code may not use the openpilot trademark and must keep the full safety test suite passing. Forks must not disable or weaken driver monitoring. Breaking these rules can get users banned from comma's servers.[7]
Data collection
By default openpilot uploads driving data (road-facing cameras, CAN, GPS, IMU and system logs) to comma's servers, where it is used to train models. The driver camera and microphone are logged only if the user opts in, and users can disable data collection.[3] comma said in August 2026 that its fleet logs "nearly one million driving minutes every day" and that about 15% of drives are ingested into training.[21]
Supported vehicles and fleet
The supported-cars list on 30 October 2026 had 335 entries: 334 cars across 26 makes, plus the comma body robot. Hyundai and Toyota had the most entries (45 each), followed by Kia (40), Volkswagen (38) and Honda (36).[8] comma's marketing page on the same date claimed "350+ car models", "300+ million miles driven", "20,000+ active users", "1000+ contributors" and that "56%" of miles driven are engaged.[9] Electrek reported in September 2026 that comma says more than 30,000 cars use its devices and that they have logged over 400 million miles.[31] These are company-reported figures, and they vary between comma's own pages.
Forks and community
Because openpilot is MIT-licensed, community forks change its behavior and car coverage. Two of the best known are sunnypilot, whose repository says it "complies with the safety policy from comma.ai's openpilot as accurately as possible", and FrogPilot, which calls itself a "highly customizable fork of openpilot".[35][36] As of 30 October 2026 the sunnypilot repository had 2,158 GitHub stars and FrogPilot 567.[35][36] Community contributors also write many car ports: the release notes credit individual developers for most new vehicles, including the Tesla Model 3 and Y port by lukasloetkolben and the VW ID.4 port by DaHansi.[5][1]
Reception and evaluations
Consumer Reports (2020)
In a report dated 16 November 2020, Consumer Reports rated 18 active driving assistance systems, 17 of them factory-fitted and one aftermarket: the comma two running openpilot on a 2020 Toyota Corolla LE. The comma two received the highest overall score (78), ahead of Cadillac Super Cruise (69) and Tesla Autopilot (57).[30] Consumer Reports said it "does not endorse after-market modifications to all consumers" but included the system as a comparison for the industry. It singled out the infrared driver-monitoring cameras in Super Cruise and the comma two as "the best driver monitors".[30]
Academic analysis
Researchers outside comma have studied openpilot as a production example of end-to-end driving. In "Level 2 Autonomous Driving on a Single Device: Diving into the Devils of Openpilot" (arXiv:2206.08176, June 2022), Li Chen and colleagues reverse-engineered the "Supercombo" model of the time (an EfficientNet-B2 backbone with a GRU and fully connected heads) and re-implemented it as "OP-Deepdive". They reported that a low-cost device "can indeed achieve most L2 functionalities".[28] Meriel von Stein and Sebastian Elbaum used openpilot as a case study for neural-network falsification at the IEEE/ACM ASE 2022 conference.[29] comma has published its own datasets and papers, including the commaVQ dataset of 100,000 minutes of compressed driving video and the 2025 world-model paper.[37][26]
Regulation and safety scrutiny
NHTSA preliminary evaluation (2026)
On 21 September 2026 NHTSA's Office of Defects Investigation opened Preliminary Evaluation PE26007 covering the comma three, comma 3X, comma four and openpilot, an estimated 30,000 products.[31][32] The agency identified five crashes in which vehicles fitted with comma devices struck stopped or slow-moving vehicles in their own lane. Two of the crashes killed three people, and four involved injuries to 11 others.[31][32] According to Electrek's reading of the filing, ODI confirmed that the comma system was on or engaged in "multiple crashes", and its early review suggests openpilot "may not have adequately detected or responded to the in-lane vehicles".[31] In its own crash report on a fatal February 2026 crash in Louisiana, comma said the device "appears to have been running 3rd party non-comma software". NHTSA said it would evaluate any fork involved and consider which components it shares with openpilot.[31][32] A preliminary evaluation is not a defect finding, and NHTSA had not concluded that comma's system caused the crashes.[32]
Continue reading
- World modelA world model is an artificial intelligence system that learns an internal representation of how an environment works, enabling it to predict future states, simulate the consequences of actions, and support…Mentioned 19 times above
- comma.aicomma.ai, Inc. is an American advanced driver-assistance technology company headquartered in San Diego, California.Mentioned 5 times above
- tinygradtinygrad is an open-source deep learning framework written primarily in Python that aims to occupy the space between Andrej Karpathy's pedagogical micrograd and full-scale production stacks like PyTorch.Mentioned 5 times above
- George HotzGeorge Hotz (born October 2, 1989), known online as "geohot," is an American software engineer, security researcher, and entrepreneur best known for being the first person to carrier unlock Apple's original…Mentioned twice above
- Advanced Driver-Assistance SystemsAdvanced Driver-Assistance Systems (ADAS) are electronic technologies that help drivers operate, steer, brake, and park a vehicle by warning of hazards or taking momentary or sustained control of the driving…Listed in See also
- Autonomous vehicleAn autonomous vehicle, also known as a self-driving car, driverless car, or robotic vehicle, is a vehicle that uses artificial intelligence, sensors, and software to navigate and operate without human input.Listed in See also
More from See also
More to read
Topics:Autonomous VehiclesOpen Source AIReinforcement LearningWorld Models
References
- ^1 ^2 ^3 ^4 ^5 ^6 ^7 ^8 ^9 ^10 ^11 ^12 ^13 ^14 ^15 ^16 ^17 ^18 ^19 ^20 ^21 ^22 ^23 ^24 ^25 ^26 ^27 ^28 ^29 ^30 ^31 ^32openpilot 0.11.2. comma.ai blog, 23 October 2026.
- ^1 ^2 ^3 ^4 ^5comma (@comma_ai): "openpilot 0.11.2 ships today" thread. X, 23 October 2026.
- ^1 ^2 ^3 ^4 ^5 ^6 ^7 ^8commaai/openpilot README. GitHub, accessed 30 October 2026.
- ^1 ^2 ^3commaai/openpilot repository metadata. GitHub REST API, accessed 30 October 2026.
- ^1 ^2 ^3 ^4 ^5 ^6 ^7 ^8 ^9 ^10 ^11 ^12 ^13 ^14 ^15openpilot RELEASES.md. GitHub, accessed 30 October 2026.
- ^1 ^2 ^3openpilot v0.11.2 release. GitHub, 23 October 2026.
- ^1 ^2 ^3 ^4 ^5 ^6openpilot SAFETY.md. GitHub, accessed 30 October 2026.
- ^1 ^2 ^3Supported Cars. openpilot docs (generated from docs/CARS.md), accessed 30 October 2026.
- ^1 ^2 ^3openpilot. comma.ai, accessed 30 October 2026.
- ^1 ^2 ^3 ^4George Hotz is giving away the code behind his self-driving car project. The Verge, 30 November 2016.
- ^1 ^2 ^3Comma.ai cancels the Comma One following NHTSA letter. Darrell Etherington, TechCrunch, 28 October 2016.
- ^1 ^2 ^3 ^4End-to-end lateral planning. comma.ai blog, 29 March 2021.
- ^1 ^2 ^3openpilot 0.9.0. comma.ai blog, 20 November 2022.
- ^1 ^2 ^3openpilot 0.9.8. comma.ai blog, 18 March 2025.
- ^1 ^2openpilot 0.9.9. comma.ai blog, 19 June 2025.
- ^1 ^2 ^3 ^4 ^5openpilot 0.10. comma.ai blog, 21 August 2025.
- ^1 ^2 ^3openpilot 0.10.1. comma.ai blog, 28 October 2025.
- ^openpilot 0.10.3. comma.ai blog, 21 December 2025.
- ^1 ^2 ^3 ^4 ^5 ^6 ^7 ^8 ^9openpilot 0.11. comma.ai blog, 17 March 2026.
- ^1 ^2openpilot 0.11.1. comma.ai blog, 5 June 2026.
- ^1 ^2 ^3Introducing chestnut. comma.ai blog, 12 August 2026.
- ^chestnut. comma shop, accessed 30 October 2026.
- ^Introducing the comma 3X. comma.ai blog, 12 October 2023.
- ^Introducing the comma four. comma.ai blog, 25 November 2025.
- ^Learning a Driving Simulator. Eder Santana and George Hotz, arXiv:1608.01230, 3 August 2016.
- ^1 ^2 ^3Learning to Drive from a World Model. Mitchell Goff, Greg Hogan, George Hotz, Armand du Parc Locmaria, Kacper Raczy, Harald Schäfer, Adeeb Shihadeh, Weixing Zhang and Yassine Yousfi, arXiv:2504.19077, 27 April 2025.
- ^Learning to Drive from a World Model (companion post). comma.ai blog, 2025.
- ^Level 2 Autonomous Driving on a Single Device: Diving into the Devils of Openpilot. Li Chen et al., arXiv:2206.08176, 16 June 2022.
- ^Finding Property Violations through Network Falsification: Challenges, Adaptations and Lessons Learned from OpenPilot. Meriel von Stein and Sebastian Elbaum, Proceedings of the 37th IEEE/ACM International Conference on Automated Software Engineering (ASE 2022), October 2022.
- ^1 ^2Active Driving Assistance Systems: Test Results and Design Recommendations. Consumer Reports, 16 November 2020.
- ^1 ^2 ^3 ^4 ^5NHTSA investigates comma.ai's openpilot over 5 crashes that killed 3. Fred Lambert, Electrek, 24 September 2026.
- ^1 ^2 ^3 ^4Feds Investigate Aftermarket Hands-Free Driving Tech After 5 Crashes, 3 Reported Deaths. Yahoo Autos, 24 September 2026.
- ^commaai/openpilot_driving_models. Hugging Face, accessed 30 October 2026.
- ^commaai/opendbc README (safety model and code rigor). GitHub, accessed 30 October 2026.
- ^1 ^2sunnypilot/sunnypilot. GitHub, accessed 30 October 2026.
- ^1 ^2FrogAi/FrogPilot. GitHub, accessed 30 October 2026.
- ^commaai/commavq. GitHub, accessed 30 October 2026.
Improve this article
Add missing citations, update stale details, or write a clearer explanation. Anyone can edit: changes go live when you publish, and every edit is checked by an editor.
1 revision · v1 · 4,315 words · full history
Fact-checks are independent of edits: a reviewer re-verifies the article against its sources and stamps the date. How we verify
Research and drafting on this wiki are AI-assisted, under named human editorial standards. How AI is used here
Reviewer note: xg30 independent verification (46 sources, ~175 claims: blog.comma.ai release posts, GitHub RELEASES.md/API, docs.comma.ai CARS, arXiv/ASE papers, Consumer Reports, NHTSA PE26007 coverage); 1 material (world-model training timeline in lead) and 7 minor fixes applied pre-publish
Cite this page: AI Wiki. "openpilot." aiwiki.ai, updated 30 Oct 2026, fact-checked 30 Oct 2026. CC BY 4.0. https://aiwiki.ai/wiki/openpilot