

Mobile manipulation
Mobile manipulation is the branch of robotics concerned with robots that combine a mobile base (wheeled, tracked or legged) with one or more manipulator arms, so that the same machine can travel through an environment and physically act on objects in it. Such a robot is called a mobile manipulator. Oussama Khatib's 1999 article on the subject described mobile manipulation as key to robot applications in space, underwater, construction and service settings, and centred the research problem on coordinating the vehicle with the arm, controlling compliant contact, and getting several platforms to cooperate on one load.[1] Later research shifted toward homes and offices, where a robot has to find, grasp and move everyday objects in cluttered rooms built for people.[2][6]
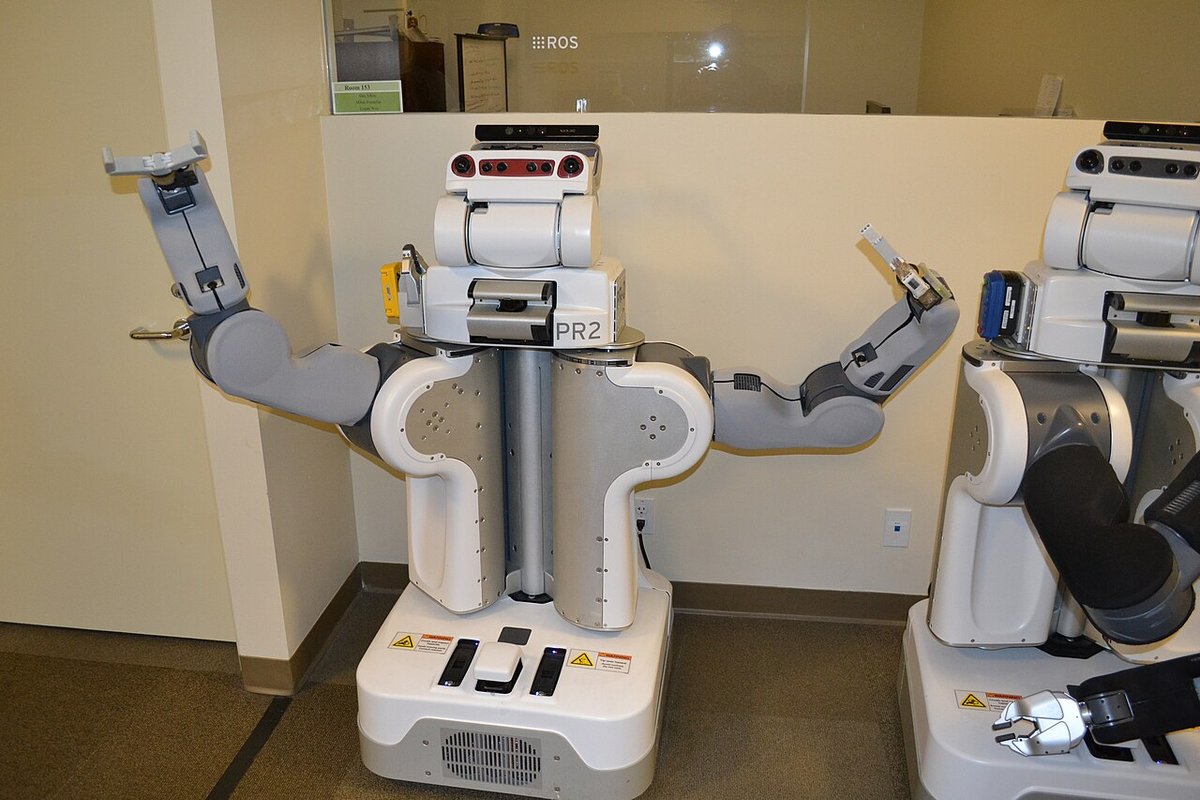
Mobile manipulators have long been expensive research machines. Willow Garage's PR2 sold for $400,000 in 2010,[4] and in a 2022 paper Hello Robot's designers observed that mobile manipulators had so far been used mainly in research laboratories, with home and office use not yet realized and industrial use still nascent.[6] Since about 2021 cheaper hardware, low-cost teleoperation rigs for collecting demonstrations, large language models used as task planners, and vision-language-action models trained on data from many homes have made mobile manipulation one of the most active areas of robot learning.[7][10][15] Commercial mobile manipulators include Boston Dynamics' Stretch, sold for unloading trucks in warehouses, and the arm offered for the company's Spot quadruped.[17][19]
Definition and scope
A fixed industrial arm works inside a reach envelope set by where it is bolted down. Putting the arm on a moving base removes that limit but couples two systems: the base decides where the arm can reach, and arm motion (especially with a load) changes the stability of the base.[1][6] Khatib's group at Stanford developed control strategies for "vehicle-arm coordination" on two holonomic platforms built with Oak Ridge National Laboratory and Nomadic Technologies,[1] and the 2022 design paper for Hello Robot's Stretch stresses that its mobile base "plays a critical role in manipulation" because the lift and telescoping arm only position the end of the arm within a vertical plane.[6]
The term covers a wide range of hardware:
| Configuration | Examples | Notes |
|---|---|---|
| Wheeled base with one arm | HERB, Toyota HSR, Fetch, Everyday Robots helper robot, Stretch | The most common research form[2][5][6][10] |
| Wheeled base with two arms | PR2, Mobile ALOHA, Galaxea R1, Physical Intelligence's test robots | Used for bimanual household tasks[3][7][9][15] |
| Legged base with an arm | Spot with Spot Arm | Arm sold as a payload for the quadruped[17] |
| Industrial wheeled base with a heavy arm | Boston Dynamics Stretch | Built for unloading trucks and containers[18] |
Robots with a human-like upper body, on legs or wheels, are covered under humanoid robot.
History
Early research platforms
In the 1990s, mobile manipulation research concentrated on control. Khatib's 1999 article in Robotics and Autonomous Systems discussed giving robots "assistance" capabilities to help workers carry out physical operations, and described control strategies for vehicle-arm coordination, compliant motion tasks and cooperative manipulation between several mobile platforms.[1] Those strategies ran on two holonomic mobile platforms built at Stanford.[1] A holonomic base can move in any planar direction and rotate at the same time. A 2000 paper by Robert Holmberg and Khatib on a holonomic robot for mobile manipulation is the source of the powered-caster drive used in the open-source TidyBot++ base of 2024.[8]
Home-assistant robots of the 2000s and 2010s
By the late 2000s the target environment had shifted to the home. HERB (Home Exploring Robotic Butler), built by Intel Research Pittsburgh and Carnegie Mellon's Robotics Institute, combined a Segway RMP200 mobile base with a Barrett WAM arm.[2] Its 2009 journal paper argued that tasks people most wanted help with, such as cleaning, dish washing, laundry and moving heavy things, all required manipulating objects, which no robot then on the market could do.[2] The paper presented algorithms for searching for objects, navigating cluttered indoor scenes, recognizing objects in clutter, opening doors with caging grasps and planning grasps.[2]
Willow Garage's PR2, a two-armed robot on a mobile base, became the best-known research mobile manipulator of the period. In May 2010 Willow Garage announced that it would give 11 PR2 robots to universities and companies in the United States, Europe and Japan through its PR2 Beta Program; IEEE Spectrum described the robot as an open platform with a mobile base, two arms, many sensors and 16 CPU cores, running the BSD-licensed Robot Operating System (ROS).[3] Willow Garage put the PR2 on general sale in September 2010 for $400,000, with a discounted $280,000 version for groups that could show a record of contributing to open-source robotics software.[4]
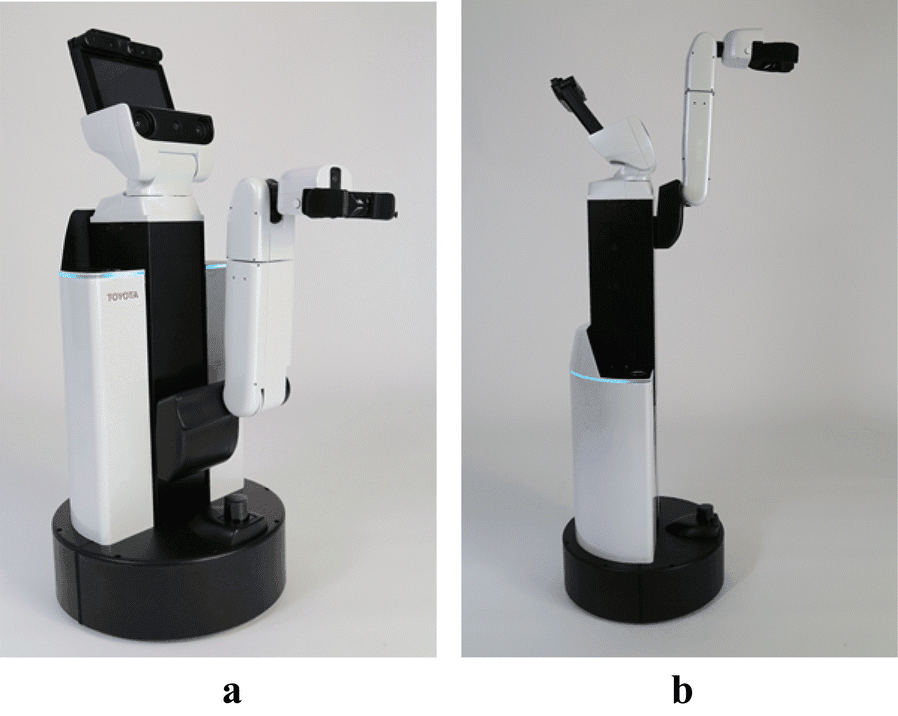
Toyota developed the Human Support Robot (HSR) as a compact, safe platform that could operate in real homes, with an omnidirectional base driven by a dual-wheel caster mechanism and a whole-body motion control system.[5] Toyota supplied the robot to research institutes to build a shared developer community; by 30 November 2018 HSR was in use at 44 sites in 12 countries, and it had been adopted as a standard platform for the RoboCup@Home competition and the World Robot Summit.[5]
Smaller and cheaper platforms
The Stretch design paper compared five commercial mobile manipulators by width, weight and price:[6]
| Robot | Maker | Width | Weight | Price (as listed in the paper) |
|---|---|---|---|---|
| Stretch RE1 | Hello Robot | 34 cm | 23 kg | about $20,000 |
| HSR | Toyota | 43 cm | 37 kg | not available |
| Fetch | Fetch Robotics | 51 cm | 113 kg | about $100,000 |
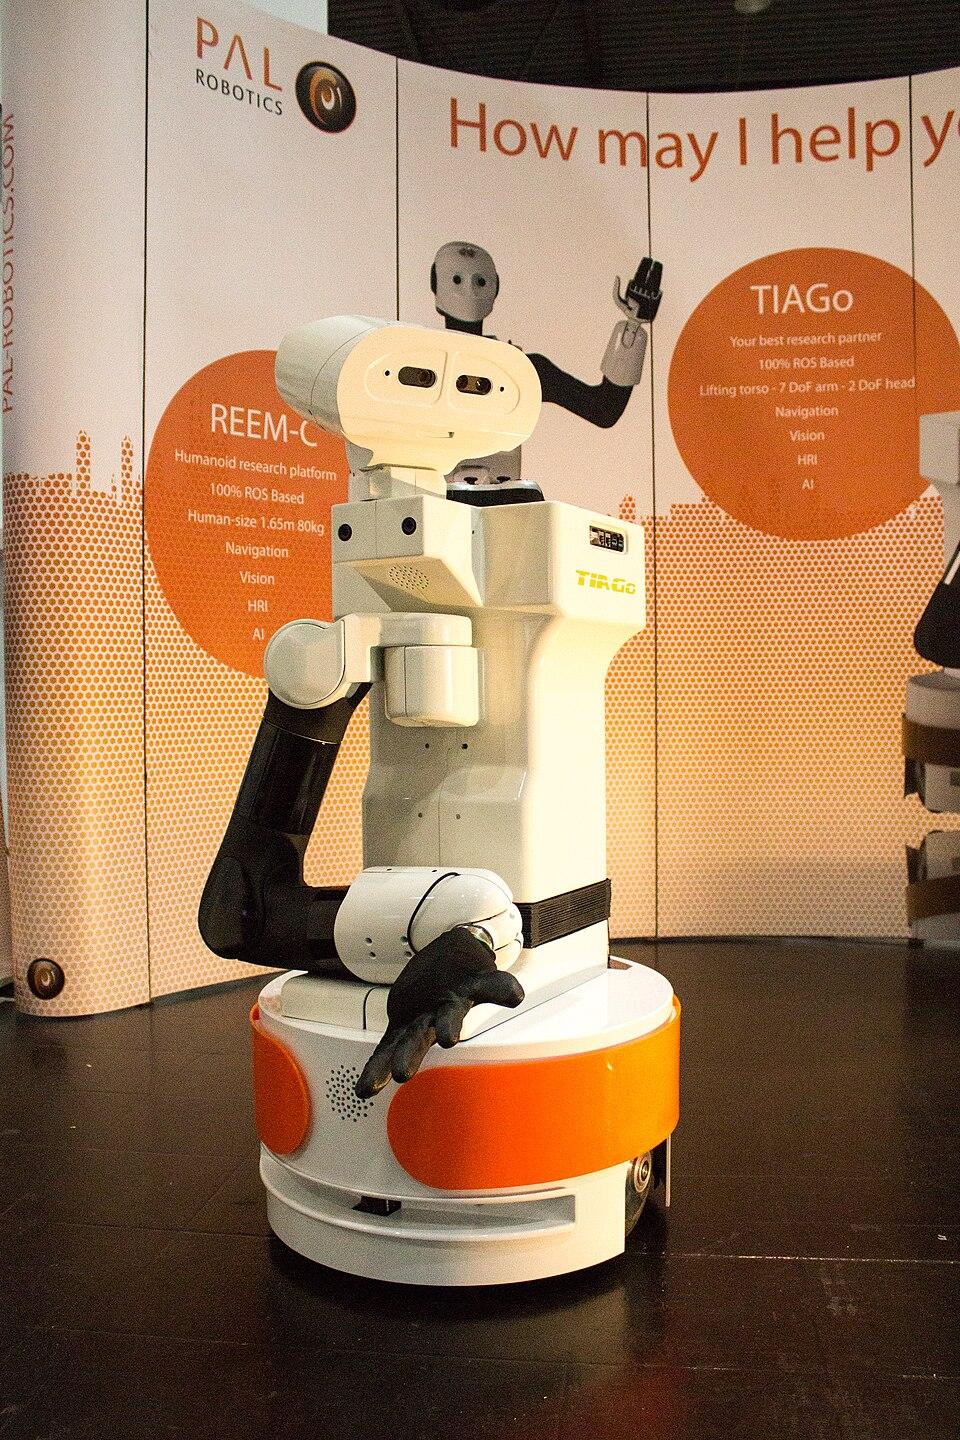
| TIAGo Steel | PAL Robotics | 54 cm | 70 kg | about $56,000 |
| PR2 | Willow Garage | 67 cm | 220 kg | $400,000 |
Stretch, designed by Charles C. Kemp, Aaron Edsinger and colleagues, took the iRobot Roomba as its model of a minimal, widely adopted home robot.[6] Instead of an articulated arm, the original design (the Stretch RE1) used a two-wheeled differential-drive base, a vertical lift and a horizontal telescoping arm, a layout chosen to give Cartesian motion at the end of the arm with few actuators.[6] Two prototypes were built at Georgia Tech's Healthcare Robotics Lab between October 2016 and July 2017, and Hello Robot then built eight more prototypes between August 2017 and May 2020, testing them in a real home in Atlanta.[6] Stretch became a common platform for academic home-robot research: the HomeRobot benchmark and the OK-Robot system both run on it.[13][14] Stretch 3 went on sale in February 2024 for $24,950.[22] Hello Robot announced Stretch 4 in May 2026,[25] and as of November 2026 lists it at $29,950.[23] The Stretch 4 product page describes the robot as omnidirectional and gives a weight of 46 kg (33 kg with the ballast removed for transport) and a height of 160 cm.[24]
Academic groups also built their own low-cost platforms for collecting training data. Stanford's Mobile ALOHA (January 2024) mounted a bimanual ALOHA teleoperation rig on a wheeled base for a total budget of $32,000, and its authors noted that off-the-shelf bimanual mobile manipulators such as the PR2 and TIAGo can cost more than $200,000.[7] TidyBot++ (CoRL 2024), from Stanford and Princeton, is an open-source holonomic base costing $5,000 to $6,000 that can carry different arms; the authors paired it with a Kinova Gen3 arm and a mobile-phone teleoperation interface.[8] The BEHAVIOR Robot Suite from Stanford (CoRL 2025) uses the Galaxea R1, a wheeled robot with two 6-degree-of-freedom arms, a 4-degree-of-freedom torso and an omnidirectional base, and controls it with JoyLo, a teleoperation interface built from Nintendo Joy-Con controllers on small kinematic-twin arms.[9]
Technical problems
Coordinating base and arm
A mobile manipulator has to coordinate its base with its arm, the problem Khatib's group studied as vehicle-arm coordination.[1] HERB's authors developed planners for manipulation on pose and torque constraint manifolds and noted that the robot description given to such a planner could include both the arm and the base.[2] Learning-based systems increasingly output base and arm commands together. Mobile ALOHA's policy predicts the base's linear and angular velocity along with the arm joints,[7] and Physical Intelligence's π0.5 directly commands both arms, the grippers, a torso lift and the base velocity at 50 Hz, an 18- or 19-dimensional action space depending on the robot, without a separate trajectory planner.[15] See whole-body control.
Holonomic and nonholonomic bases
Many research bases use differential drive, the wheelchair-like arrangement of two powered wheels. Such bases are nonholonomic: they cannot move sideways, so a small lateral correction requires a multi-point manoeuvre.[8] The TidyBot++ authors argue that household tasks like opening doors and cabinets often call for sideways base motion, and that a holonomic base makes teleoperation easier and simplifies policy learning.[8] Their base uses the powered-caster drive described by Holmberg and Khatib: four motorized casters that can both roll and steer, which the authors liken to a motorized office chair.[8] The original Stretch design took the opposite approach: it kept differential drive but extended its telescoping arm at right angles to the base's direction of travel, so that in its manipulation mode, driving the base forward or back moves the gripper sideways relative to the arm.[6] Hello Robot describes the later Stretch 4 as omnidirectional.[24]
Size, weight and stability
A lighter, narrower robot is easier to move through doorways and safer in a collision, but it tips over more easily when the arm reaches out or lifts a load. The Stretch paper names static stability as the dominant design concern once weight and base size are reduced, and justifies its geometry with mathematical models of stability and with human body measurements, such as reaching the floor and countertops.[6] Mobile ALOHA carries a 14 kg battery at its base that also serves as a counterweight against tipping.[7]
Perception and generalization
Homes are cluttered and change over time, so a home robot has to navigate dynamic indoor scenes, recognize objects in clutter and grasp items it has never seen.[2][13] The HomeRobot authors describe open-vocabulary mobile manipulation (OVMM), picking up any object in an unseen environment and placing it in a commanded location, as a problem that combines perception, language understanding, navigation and manipulation, with integration being a challenge of its own.[13] The OK-Robot authors reported that the most important lesson of their system was the role of small details when connecting pretrained vision-language models to robot navigation and grasping modules.[14]
Research approaches
Classical pipelines and reinforcement learning
Early home robots such as HERB were built from separate modules for localization, object recognition, grasp planning and motion planning.[2] Simulation made it possible to compare these sense-plan-act pipelines with learned policies. Habitat 2.0 (2021), from Facebook AI Research and academic partners, simulated a Fetch mobile manipulator in reconfigurable apartments and introduced the Home Assistant Benchmark, with tasks such as tidying a house, preparing groceries and setting a table.[16] Its authors found that flat reinforcement learning policies did worse than hierarchical ones, that chains of independent skills suffered from "hand-off problems", and that sense-plan-act pipelines were more brittle than RL policies.[16] See AI Habitat.
Language models as planners
Google's SayCan (2022) used a large language model to choose which of a robot's pretrained skills to run next, weighting each candidate by a learned value function that estimated whether the skill could succeed in the current scene.[10] It ran on a mobile manipulator from Everyday Robots, an Alphabet subsidiary, with a 7-degree-of-freedom arm and a two-fingered gripper, working in office kitchens. Across 101 instructions, the version using PaLM chose a correct sequence of skills 84% of the time and executed it successfully 74% of the time in the mock kitchen.[10] TidyBot (2023), from Princeton, Stanford, Google and other institutions, used an LLM to summarize a person's tidying preferences from a few examples; it reached 91.2% accuracy on unseen objects in a text benchmark and put away 85.0% of objects in real-world tests on a holonomic mobile manipulator.[12]
Open-vocabulary mobile manipulation
HomeRobot (2023), from Georgia Tech, Meta's FAIR, Carnegie Mellon and Simon Fraser University, defined an OVMM benchmark with a simulated component and a real-world component built around the Hello Robot Stretch, and was run as a NeurIPS 2023 competition. Its baselines reached a 20% success rate in the real world.[13] OK-Robot (2024), from New York University and Meta, combined pretrained "open knowledge" models, including OWL-ViT, CLIP, Lang-SAM and AnyGrasp, with navigation and grasping primitives, and needed no task-specific training; objects are located in a semantic map built while the home is scanned in advance. In tests in 10 real homes it succeeded at 58.5% of open-ended pick-and-drop tasks, which the authors put at nearly 1.8 times the best earlier result, and at 82% in cleaner, less cluttered homes.[14]
Imitation learning from teleoperation
Imitation learning trains a policy to copy human demonstrations. The Mobile ALOHA authors named the lack of affordable, plug-and-play hardware for whole-body teleoperation as one of two main obstacles to using it for bimanual mobile manipulation.[7] Mobile ALOHA's operator is physically tethered to the base and moves it while controlling the robot's arms by hand. With 50 demonstrations per task, its authors found that co-training with existing static ALOHA datasets could raise success rates by up to 90%, enough for the robot to call and enter an elevator or rinse a pan on its own.[7] TidyBot++ uses a phone-based interface,[8] and BRS uses its Joy-Con-based JoyLo rig and a learning algorithm for whole-body visuomotor policies, which it evaluated on five household tasks in real homes.[9] Methods such as Action Chunking with Transformers and Diffusion Policy are commonly used to learn from such data.[7]
Large robot policies
Google's RT-1 (December 2022) trained a transformer policy on about 130,000 demonstrations of more than 700 tasks, collected over 17 months with a fleet of 13 Everyday Robots mobile manipulators, and reported 97% success on its training instructions.[11] Physical Intelligence's π0.5 (April 2025), built on π0, was trained on about 400 hours of mobile manipulator data from about 100 homes plus data from non-mobile robots, laboratory tasks and the web; in the first training phase, 97.6% of examples did not come from mobile manipulators doing household tasks.[15] The authors reported that π0.5 could clean kitchens and bedrooms in homes that were not in its training data, carrying out multi-stage tasks lasting 10 to 15 minutes, and evaluated it in three such homes.[15] See physical AI.
Benchmarks and competitions
| Benchmark or competition | Robot | Task focus |
|---|---|---|
| RoboCup@Home (standard platform) | Toyota HSR | Domestic service tasks[5] |
| World Robot Summit | Toyota HSR | Domestic service tasks[5] |
| Habitat 2.0 Home Assistant Benchmark (2021) | Fetch (simulated) | Rearrangement in apartments[16] |
| HomeRobot OVMM (2023) | Hello Robot Stretch, simulated and real | Find, pick and place named objects[13] |
Commercial and industrial use
Alphabet's Everyday Robots taught more than a hundred wheeled, one-armed robots to clean cafeteria tables, and its robots were used in the SayCan and RT-1 research.[10][11][21] In February 2023, amid Alphabet's layoffs, The Robot Report (citing Wired) reported that the subsidiary was being shut down; it had employed over 200 people, and some of its technology and team were to be consolidated into existing robotics projects.[21]
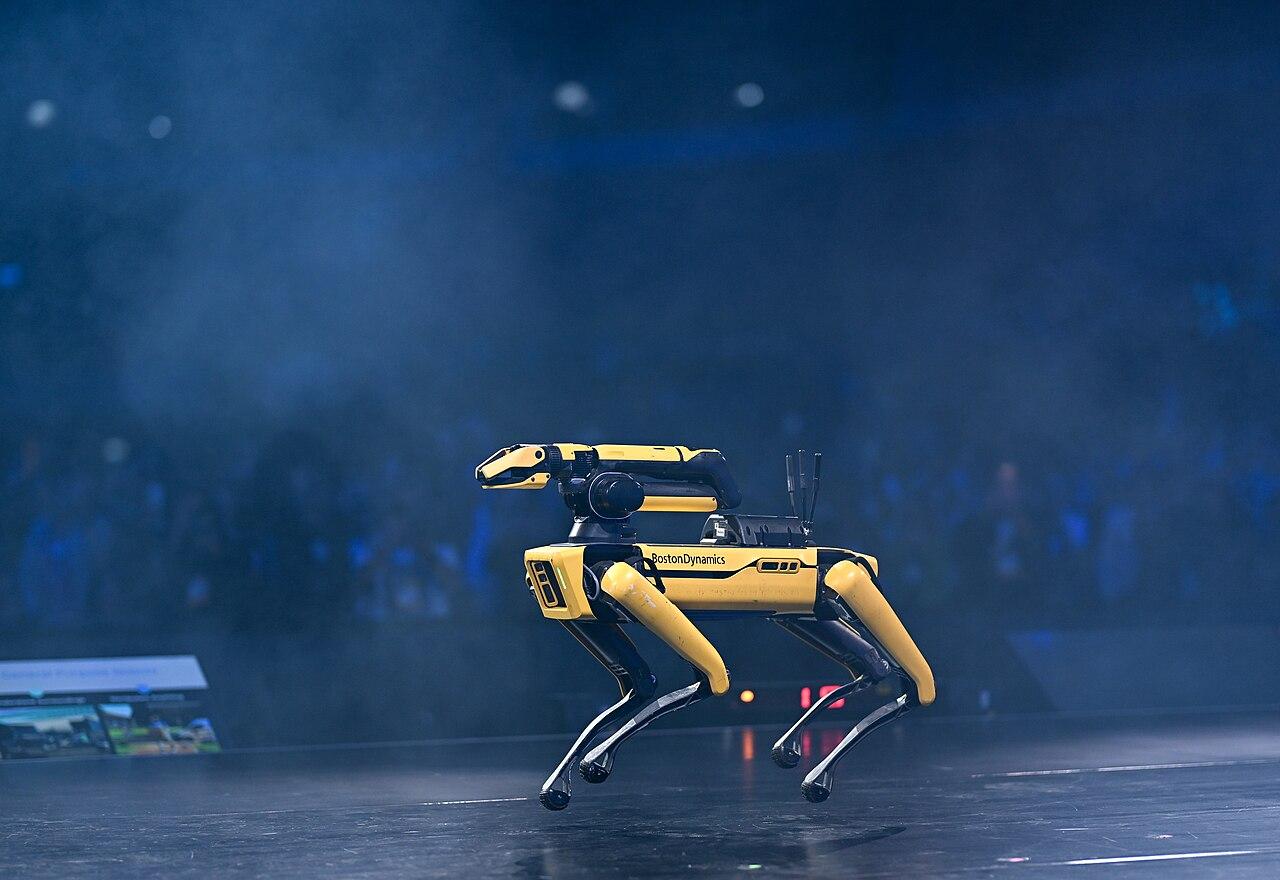
Boston Dynamics released the Spot Arm for its Spot quadruped on 2 February 2021. The company said the arm could grasp, lift, carry, place and drag objects, open and close valves, pull levers, turn handles and knobs, and, working with the robot's body, open push and pull doors, operated either by remote telemanipulation or with semi-autonomous actions.[17]
Boston Dynamics' Stretch is a warehouse mobile manipulator with an omnidirectional base, a single large arm and a suction gripper, designed to unload boxes from trucks and shipping containers.[18] The company made it commercially available on 28 March 2022, naming DHL Supply Chain, Gap, H&M and Performance Team as early customers; DHL placed a $15 million pre-order.[19] In November 2026 Boston Dynamics unveiled Stretch Gen 2, which the company says can unload up to 1,000 cases per hour, a figure The Robot Report notes depends on case weight and how neatly the cases are stacked.[20]
Hello Robot has said that home consumers are not yet its market: in a 2024 interview Kemp said the company's market was "not yet consumers in the home".[22]
Timeline
| Date | Event |
|---|---|
| 1999 | Khatib's "Mobile manipulation: The robotic assistant" published[1] |
| November 2009 | HERB journal paper published online[2] |
| May 2010 | Willow Garage announces 11 PR2 robots for its Beta Program[3] |
| September 2010 | PR2 goes on sale for $400,000[4] |
| February 2021 | Boston Dynamics releases Spot Arm[17] |
| June 2021 | Habitat 2.0 and the Home Assistant Benchmark released[16] |
| March 2022 | Boston Dynamics Stretch commercially available[19] |
| April 2022 | SayCan paper released[10] |
| December 2022 | RT-1 paper released[11] |
| February 2023 | Alphabet closes Everyday Robots[21] |
| June 2023 | HomeRobot OVMM benchmark released[13] |
| January 2024 | Mobile ALOHA and OK-Robot released[7][14] |
| February 2024 | Hello Robot Stretch 3 goes on sale[22] |
| April 2025 | Physical Intelligence publishes π0.5[15] |
| May 2026 | Hello Robot announces Stretch 4[25] |
| November 2026 | Boston Dynamics unveils Stretch Gen 2[20] |
Continue reading
- Mobile ALOHAMobile ALOHA is an open-source, low-cost system for collecting bimanual mobile manipulation data and learning household tasks from it, developed at Stanford University by Zipeng Fu, Tony Z. ZhaoMentioned 7 times above
- Toyota Human Support Robot (HSR)The Human Support Robot (often abbreviated HSR) is a compact, single-armed mobile manipulation robot built by Toyota Motor Corporation as a standardised research platform for domestic and assistive robotics.Mentioned 7 times above
- Spot (robot)Spot is a quadruped robot developed by Boston Dynamics, a four-legged, all-electric mobile platform marketed as "the agile mobile robot" for automating sensing and inspection in industrial environments.Mentioned 6 times above
- TIAGo (PAL Robotics)TIAGo (Take It And Go) is a modular mobile manipulator service robot developed by PAL Robotics, a Spanish robotics company headquartered in Barcelona.Mentioned twice above
- Robot learningRobot learning studies how robots acquire or improve behavior from data and experience.Listed in See also
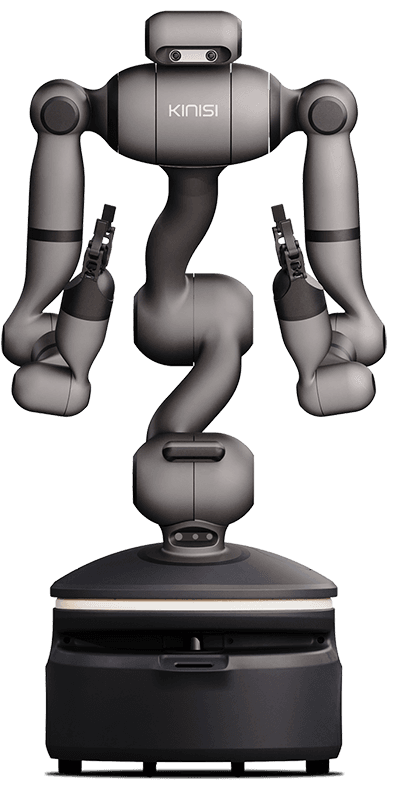
- Kinisi KR1The Kinisi KR1, also marketed as the Kinisi 01, is a wheeled mobile manipulator (a humanoid-style upper body mounted on an omnidirectional wheeled base) developed by Kinisi Robotics for warehouse automation…Listed in See also
More from See also
More to read
References
- ^1 ^2 ^3 ^4 ^5 ^6 ^7Oussama Khatib. "Mobile manipulation: The robotic assistant". Robotics and Autonomous Systems, vol. 26, pp. 175-183, 1999. doi.org/...S0921-8890(98)00067-0
- ^1 ^2 ^3 ^4 ^5 ^6 ^7 ^8 ^9Siddhartha S. Srinivasa, Dave Ferguson, Casey J. Helfrich, Dmitry Berenson, Alvaro Collet, Rosen Diankov, Garratt Gallagher, Geoffrey Hollinger, James Kuffner, Michael Vande Weghe. "HERB: a home exploring robotic butler". Autonomous Robots, vol. 28, pp. 5-20, 2010 (published online 17 November 2009). doi.org/...s10514-009-9160-9
- ^1 ^2 ^3Erico Guizzo. "Willow Garage Giving Away 11 PR2 Robots Worth Over $4 Million". IEEE Spectrum, 4 May 2010. spectrum.ieee.org/...2-robots-worth-over-4-million
- ^1 ^2 ^3Paul Miller. "Willow Garage now selling the PR2 for $400k a pop". Engadget, 8 September 2010. engadget.com/...now-selling-the-pr2-for-400k-a-pop
- ^1 ^2 ^3 ^4 ^5Takashi Yamamoto, Koji Terada, Akiyoshi Ochiai, Fuminori Saito, Yoshiaki Asahara, Kazuto Murase. "Development of Human Support Robot as the research platform of a domestic mobile manipulator". ROBOMECH Journal, vol. 6, article 4, 2019. doi.org/...s40648-019-0132-3
- ^1 ^2 ^3 ^4 ^5 ^6 ^7 ^8 ^9 ^10 ^11Charles C. Kemp, Aaron Edsinger, Henry M. Clever, Blaine Matulevich. "The Design of Stretch: A Compact, Lightweight Mobile Manipulator for Indoor Human Environments". IEEE International Conference on Robotics and Automation (ICRA), 2022. arxiv.org/...2109.10892
- ^1 ^2 ^3 ^4 ^5 ^6 ^7 ^8 ^9Zipeng Fu, Tony Z. Zhao, Chelsea Finn. "Mobile ALOHA: Learning Bimanual Mobile Manipulation with Low-Cost Whole-Body Teleoperation". arXiv:2401.02117, 4 January 2024. arxiv.org/...2401.02117
- ^1 ^2 ^3 ^4 ^5 ^6Jimmy Wu, William Chong, Robert Holmberg, Aaditya Prasad, Yihuai Gao, Oussama Khatib, Shuran Song, Szymon Rusinkiewicz, Jeannette Bohg. "TidyBot++: An Open-Source Holonomic Mobile Manipulator for Robot Learning". Conference on Robot Learning (CoRL), 2024. arxiv.org/...2412.10447
- ^1 ^2 ^3Yunfan Jiang, Ruohan Zhang, Josiah Wong, Chen Wang, Yanjie Ze, Hang Yin, Cem Gokmen, Shuran Song, Jiajun Wu, Li Fei-Fei. "BEHAVIOR Robot Suite: Streamlining Real-World Whole-Body Manipulation for Everyday Household Activities". Conference on Robot Learning (CoRL), 2025. arxiv.org/...2503.05652
- ^1 ^2 ^3 ^4 ^5 ^6Michael Ahn et al. "Do As I Can, Not As I Say: Grounding Language in Robotic Affordances". arXiv:2204.01691, 4 April 2022. arxiv.org/...2204.01691
- ^1 ^2 ^3Anthony Brohan et al. "RT-1: Robotics Transformer for Real-World Control at Scale". arXiv:2212.06817, 13 December 2022. arxiv.org/...2212.06817
- ^Jimmy Wu, Rika Antonova, Adam Kan, Marion Lepert, Andy Zeng, Shuran Song, Jeannette Bohg, Szymon Rusinkiewicz, Thomas Funkhouser. "TidyBot: Personalized Robot Assistance with Large Language Models". Autonomous Robots and IROS, 2023 (arXiv:2305.05658). arxiv.org/...2305.05658
- ^1 ^2 ^3 ^4 ^5 ^6Sriram Yenamandra et al. "HomeRobot: Open-Vocabulary Mobile Manipulation". arXiv:2306.11565, 20 June 2023. arxiv.org/...2306.11565
- ^1 ^2 ^3 ^4Peiqi Liu, Yaswanth Orru, Jay Vakil, Chris Paxton, Nur Muhammad Mahi Shafiullah, Lerrel Pinto. "OK-Robot: What Really Matters in Integrating Open-Knowledge Models for Robotics". arXiv:2401.12202, 22 January 2024. arxiv.org/...2401.12202
- ^1 ^2 ^3 ^4 ^5 ^6Physical Intelligence, Kevin Black et al. "π0.5: a Vision-Language-Action Model with Open-World Generalization". arXiv:2504.16054, 22 April 2025. arxiv.org/...2504.16054
- ^1 ^2 ^3 ^4Andrew Szot et al. "Habitat 2.0: Training Home Assistants to Rearrange their Habitat". arXiv:2106.14405, 28 June 2021. arxiv.org/...2106.14405
- ^1 ^2 ^3 ^4Boston Dynamics. "Boston Dynamics Expands Spot Product Line". Boston Dynamics press release, 2 February 2021. bostondynamics.com/...cs-expands-spot-product-line
- ^1 ^2Evan Ackerman. "A Robot for the Worst Job in the Warehouse". IEEE Spectrum, 28 December 2021. spectrum.ieee.org/warehouse-robot
- ^1 ^2 ^3Boston Dynamics. "Boston Dynamics' Stretch Robot Now Available for Commercial Purchase". Boston Dynamics press release, 28 March 2022. bostondynamics.com/...able-for-commercial-purchase
- ^1 ^2Brianna Wessling. "Boston Dynamics built Stretch Gen 2 for reliable, consistent performance". The Robot Report, 6 November 2026. therobotreport.com/...iable-consistent-performance
- ^1 ^2 ^3Brianna Wessling. "Alphabet closes Everyday Robots among layoffs". The Robot Report, 24 February 2023. therobotreport.com/...veryday-robots-among-layoffs
- ^1 ^2 ^3Evan Ackerman. "Stretch 3 Brings Us Closer to Realistic Home Robots". IEEE Spectrum, 15 February 2024. spectrum.ieee.org/hello-robot-stretch-3
- ^Hello Robot. "Purchase". Hello Robot website, accessed 18 November 2026. hello-robot.com/purchase
- ^1 ^2Hello Robot. "Stretch 4". Hello Robot website, accessed 18 November 2026. hello-robot.com/stretch-4
- ^1 ^2Hello Robot. "Stretch Community News - June 2026". Hello Robot website, 10 June 2026. hello-robot.com/stretch-community-news-june-2026
Improve this article
Add missing citations, update stale details, or write a clearer explanation. Anyone can edit: changes go live when you publish, and every edit is checked by an editor.
2 revisions · v2 · 3,598 words · full history
Fact-checks are independent of edits: a reviewer re-verifies the article against its sources and stamps the date. How we verify
Research and drafting on this wiki are AI-assisted, under named human editorial standards. How AI is used here
Reviewer note: Independent fact-check before publication on November 18, 2026: 92 claims checked against 27 cited and independent sources; 1 material and 5 minor corrections applied before publication.
Cite this page: AI Wiki. "Mobile manipulation." aiwiki.ai, updated 18 Nov 2026, fact-checked 18 Nov 2026. CC BY 4.0. https://aiwiki.ai/wiki/mobile_manipulation