

Humanoid robot hands
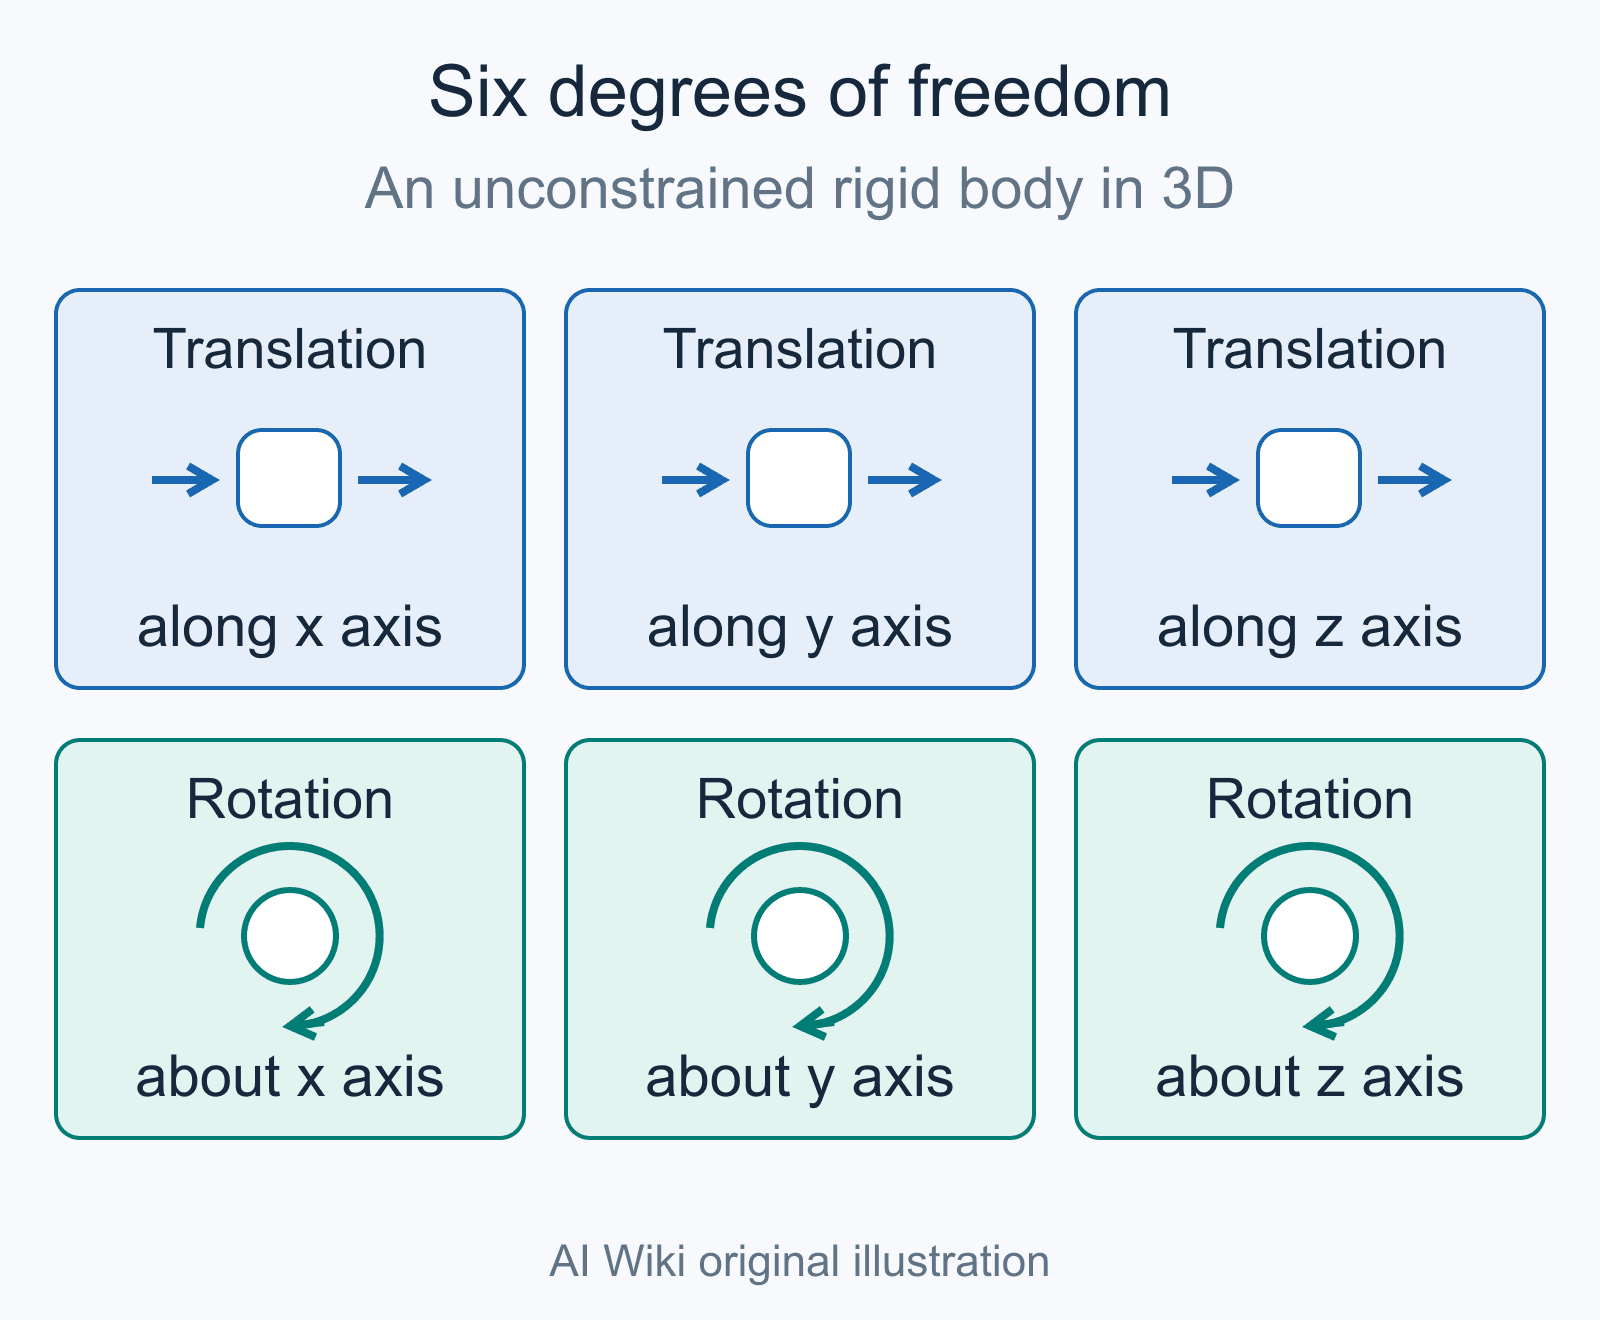
Humanoid robot hands are dexterous end effectors that replicate the grasping, manipulation, and tactile perception of the human hand, which has 27 bones and is commonly modeled with roughly 27 degrees of freedom.[4][8] They are widely regarded as the hardest subsystem in humanoid robot design, because human-like manipulation demands packing many actuators, joints, and touch sensors into a hand-sized volume while controlling them in real time. As of 2026, AI Wiki documents 120 humanoid robots with hand or gripper systems, ranging from simple two-finger grippers to fully dexterous five-finger hands with more than 20 degrees of freedom (DOF) per hand.[1]
The most capable designs now approach human anatomy: Sanctuary AI's Phoenix hand has 21 DOF and tactile sensors that detect forces as low as 5 millinewtons, close to the roughly 3-millinewton sensitivity of a human fingertip,[2] while the research-grade Shadow Dexterous Hand provides 24 degrees of freedom and over 100 sensors sampled at up to 1 kHz.[3] The field has advanced rapidly, with several robots now manipulating small objects, operating tools, and performing assembly tasks in real factory settings.
What is a humanoid robot hand?
A humanoid robot hand is an anthropomorphic end effector mounted on a robot arm to perform the grasping and fine manipulation a human hand would. Its capability is usually summarized by three numbers: the count of degrees of freedom (independently controllable joint motions), the number of fingers, and the density and sensitivity of its tactile and force sensing. A higher DOF count allows more grasp types and in-hand reorientation; richer touch sensing lets the hand modulate grip force and detect slip without vision.
What are the main types of humanoid robot hands?
Humanoid robot hands generally fall into several categories based on their design philosophy and intended use.
Dexterous hands
Dexterous hands attempt to replicate the full range of human hand motion, typically featuring five fingers with 10 or more degrees of freedom per hand. These hands can perform precision grasps (picking up small objects between fingertips) and power grasps (wrapping around larger objects). Examples include the Figure 02 (16 DOF per hand), XPENG IRON (22 DOF per hand), and Phoenix (21 DOF per hand).[1]
The main challenge with dexterous hands is controlling all the joints simultaneously while maintaining stable grasps. Most dexterous hands use a combination of tendon-driven mechanisms and direct-drive motors.
Gripper hands
Gripper-style hands use fewer fingers (typically 2-3) with simpler mechanics. They trade dexterity for reliability, grip strength, and lower cost. Robots like the Atlas (3-finger gripper) and Unitree H1 use this approach.[1] Grippers are well suited for pick-and-place tasks in structured environments.
Specialized designs
Some robots use unconventional hand designs optimized for specific applications:
- Ball grippers: Spherical gripping surfaces for adaptable grasps
- Interchangeable end effectors: Modular designs that swap between different tool heads
- Soft/compliant hands: Flexible materials that conform to object shapes, improving safety and grasp adaptability
- Cable-driven hands: Use cables (tendons) routed through the fingers, allowing actuators to be placed in the forearm for reduced hand size and weight. The MATRIX-3 uses this approach with 27 DOF cable-driven hands.[1]
- Biomimetic hands: The Clone Alpha uses water-powered artificial muscles to replicate human hand anatomy with 26 DOF per hand.[1]
Hand type distribution
| Hand type | Number of robots |
|---|---|
| Dexterous | 14 |
| Gripper | 5 |
| 20-dof dexterous hands with tactile sensing | 1 |
| Three-fingered dexterous grippers | 1 |
| Dexterous multi-finger | 1 |
| Ball gripper (no dexterous hands) | 1 |
| Interchangeable | 1 |
| Magic-hand dexterous end effector | 1 |
Complete comparison
The following table lists all 120 humanoid robots with documented hand specifications, sorted by degrees of freedom per hand.[1]
Rankings
Most degrees of freedom per hand
| Rank | Robot | Manufacturer | DOF per hand | Notes |
|---|---|---|---|---|
| 1 | MATRIX-3 | Matrix Robotics | 27 | 5 fingers |
| 2 | Clone Alpha | Clone Robotics | 26 | N/A |
| 3 | 1X Neo | 1X | 22 | 5 fingers, dexterous |
| 4 | NEO | 1X Technologies | 22 | 5 fingers |
| 5 | NEO Gamma | 1X Technologies | 22 | N/A |
| 6 | North | Sharpa | 22 | N/A |
| 7 | Optimus Gen 3 | Tesla | 22 | N/A |
| 8 | XPENG IRON | XPENG Robotics | 22 | 5 fingers, dexterous |
| 9 | Agile One | Agile Robots SE | 21 | 5 fingers |
| 10 | Phoenix | Sanctuary AI | 21 | 5 fingers, dexterous |
| 11 | Friday | Holiday Robotics | 20 | N/A |
| 12 | QUANTA X2 | X Square Robot | 20 | 5 fingers, 20-DoF dexterous hands with tactile sensing |
Highest grip force
| Rank | Robot | Manufacturer | Grip force (N) |
|---|---|---|---|
| 1 | ALLEX | WIRobotics | 40 |
| 2 | MenteeBot V3 | Mentee Robotics | 30 |
Five-finger hands
85 robots feature five-finger hands, the closest analog to the human hand.[1] Among these, the most dexterous are:
| Robot | Hand DOF | Grip force (N) | Hand type |
|---|---|---|---|
| MATRIX-3 | 27 | N/A | N/A |
| 1X Neo | 22 | N/A | dexterous |
| NEO | 22 | N/A | N/A |
| XPENG IRON | 22 | N/A | dexterous |
| Agile One | 21 | N/A | N/A |
| Phoenix | 21 | N/A | dexterous |
| QUANTA X2 | 20 | N/A | 20-DoF dexterous hands with tactile sensing |
| RoBee | 18 | N/A | N/A |
| TORA DoubleOne | 18 | N/A | N/A |
| DexBot | 17 | N/A | N/A |
| Figure 02 | 16 | N/A | dexterous |
| ALLEX | 15 | 40 | N/A |
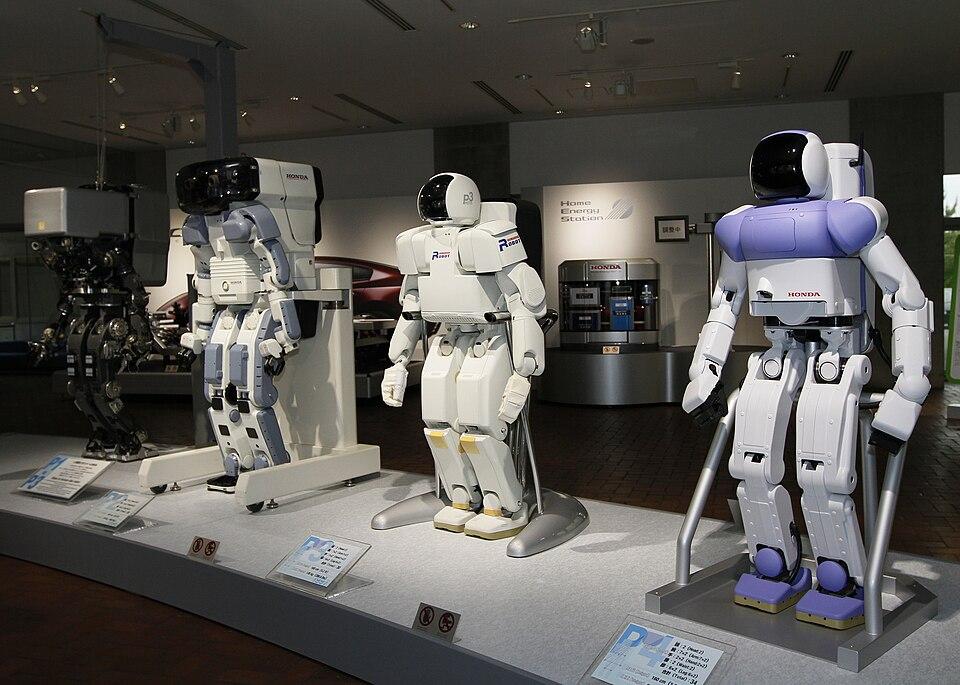
| Honda ASIMO | 13 | N/A | dexterous |
| Atom Max | 12 | N/A | N/A |
| HIVA Haiwa | 12 | N/A | N/A |
| HMND 01 Alpha Bipedal | 12 | N/A | N/A |
| Motion 2 | 12 | N/A | N/A |
How do leading dexterous hands compare?
The most-cited 2025-2026 hand designs each took a distinct approach to actuation and touch sensing. Tesla's next-generation Optimus Gen 3 hand uses a tendon-driven layout with 22 degrees of freedom in each hand (double Gen 2's 11), plus 3 more in the wrist and forearm, and 25 actuators per forearm and hand, which Basenor estimates is roughly 4.5 times Gen 2's actuator count; the fingertips add force-feedback sensors so the robot can register how hard it is gripping.[4] Figure's third-generation Figure 03 introduced proprietary fingertip sensors with 3-gram tactile sensitivity, enough to feel the weight of a paperclip, after the company concluded that off-the-shelf tactile sensors could not withstand real-world use.[5] Sanctuary AI's Phoenix hand uses hydraulic actuation, which Sanctuary says offers an order of magnitude higher power density than cable and electromechanical systems, with 21 degrees of freedom and 5-millinewton tactile sensitivity that enables blind picking and in-hand reorientation.[2][6]
The Shadow Dexterous Hand from Shadow Robot Company remains a long-standing research benchmark. It provides 24 degrees of freedom (20 actuated), with the thumb contributing 5 DOF, and ships with Shadow Tactile Fingertip sensors fitted as standard in two fingertips (upgradable to all five); the hand has over 100 sensors running at up to 1 kHz.[3]
| Hand | DOF | Actuation | Tactile sensing |
|---|---|---|---|
| Shadow Dexterous Hand | 24 (20 actuated) | Tendon (20 DC motors in the forearm) | Shadow Tactile Fingertips (2 standard, up to 5); over 100 sensors at up to 1 kHz[3] |
| Phoenix hand | 21 per hand | Hydraulic | 5 mN sensitivity, in-hand manipulation[2] |
| Figure 03 hand | Not published | Not published | 3-gram fingertip sensitivity, palm camera[5] |
| Optimus Gen 3 hand | 22 per hand | Tendon, 25 actuators per arm | Force-feedback fingertip sensors[4] |
External dexterous hand suppliers
While many humanoid robots use captive hands built by the same company that integrates the rest of the body, a parallel ecosystem of standalone dexterous hand suppliers sells hands as components to outside humanoid integrators, research labs, and industrial automation customers. These suppliers do not appear in the per-robot table above because their hands are not tied to a single platform; the same product may ship on multiple unrelated humanoids and inside teleoperation rigs.
As of mid-2026 the leading external suppliers in the high-DOF segment are concentrated in China, with the following representative products.[7][9][10][13]
| Supplier | Product | Year revealed | Active DOF | Total DOF | Palm weight | Whole-hand grasp | Drive |
|---|---|---|---|---|---|---|---|
| Xynova | Flex 1 | August 2025 | 20 | 25 | 380 g | More than 30 kg | Pure tendon |
| Xynova | Flex 2 | May 13, 2026 | Not separately disclosed | 23 | 400 g | 12 kg (4 kg rated continuous) | Hybrid cable plus direct drive |
| Wuji Tech | Wuji Hand | September 2025 | 20 | 20 | 580 g (skeleton) | 10 kg (static) | In-hand direct drive |
| Linkerbot | LinkerHand L30 | 2025 | 22 | 25 | Not published | Not published | Tendon, forearm motors |
| Inspire Robots | RH56 series | 2023 to 2025 | 6 | About 12 joints | Not published | Not published | Linkage drive |
| Shadow Robot | Shadow Hand (research) | 2005 | 20 | 24 | 4.3 kg overall | Not published | Tendon, 20 forearm DC motors (earlier pneumatic version) |
These component suppliers have become a structural feature of the humanoid market. Gasgoo, citing industry estimates, put global humanoid robot shipments above 15,000 units in 2025 (up from just over 2,000 in 2024) and, assuming two hands per robot, known dexterous hand shipments above 30,000 units; data from the China Commercial Industry Research Institute cited in the same report projects global dexterous hand capacity of about 1.41 million units and a market above 3 billion US dollars by 2030.[7] The Xynova Flex 2 in particular drew attention at launch for combining a 23-DOF hybrid drive layout with +/-0.1 mm positional repeatability, 0.05 N force control, and a 400 g palm, on a back-drivable mechanism with what Xynova calls multi-modal perception fusion and a "cerebellum"-style layer for adaptive grasping and slip detection.[10][11][12]
The supplier ecosystem also matters because it shapes the strategic decisions of integrated platform makers. Xiaomi Strategic Investment, for example, joined Xynova's December 2025 angel round (alongside CATL Capital, Zhengxuan Investment, Orient Renaissance Capital, SEARI Capital, and the L2F Ray Entrepreneur Fund) and continued adding to its stake in the March 2026 Pre-A, although it has not been confirmed whether Xiaomi's own robot hand uses Xynova technology.[9][12][13] When Genesis AI unveiled its GENE-26.5 model in May 2026, Wuji Tech described itself as a manufacturing collaborator for the Genesis Hand 1.0, a proprietary hand built to Genesis AI's design requirements, rather than the supplier of an off-the-shelf Wuji Hand.[14] Genesis AI's own technical post said the model "currently runs on a hardware platform that is already highly dexterous" and called Hand 1.0 "the next step in our hardware roadmap."[15] These cross-cutting investments and partnerships suggest the market is converging on a layered structure in which a small number of component suppliers serve a much larger number of humanoid integrators.
Key technologies
How are humanoid robot hands actuated?
Robot hands use several actuation methods:
- Tendon/cable-driven: Cables route from actuators in the forearm to the finger joints. This keeps the hand compact and lightweight while allowing high DOF counts. Used by MATRIX-3, Tesla Optimus Gen 3, and many dexterous designs.[4]
- Direct-drive motors: Small motors at each joint provide precise, responsive control. Used in many modern dexterous hands.
- Linkage mechanisms: Mechanical linkages couple finger joints so fewer motors are needed. Common in gripper designs.
- Hydraulic actuation: Pressurized fluid drives the joints. Sanctuary AI reports that its hydraulic system offers an order of magnitude higher power density than cable and electromechanical-based systems.[6]
- Artificial muscles: Pneumatic or hydraulic actuators that mimic biological muscles. The Clone Alpha uses water-powered Myofiber artificial muscles.
How do robot hands sense touch?
Effective manipulation requires rich sensory feedback:
- Force/torque sensors: Measure contact forces for stable grasping. Found in hands from Figure 02, Phoenix, and others.
- Tactile sensors: Distributed pressure sensors on fingertips and palms for detecting object shape and slip. The Shadow Dexterous Hand ships Shadow Tactile Fingertip sensors in two fingertips as standard (upgradable to all five), and Sanctuary's Phoenix detects forces as low as 5 millinewtons, approaching the roughly 3-millinewton sensitivity of a human fingertip.[2][3]
- Joint encoders: Measure finger position for precise control.
- Camera-based sensing: Some systems use fingertip or palm cameras for close-range visual feedback. The Figure 03 hand carries a camera in the palm.[5]
How are humanoid hands controlled?
Hand control approaches include:
- Position control: Commanding specific joint angles for pre-programmed grasps.
- Force control: Regulating grip force to handle fragile objects without damage.
- Imitation learning: Training hand policies from human demonstrations using teleoperation. Tactile feedback lets teleoperated pilots perform touch-driven tasks while generating high-quality training data for autonomous policies.[2]
- Reinforcement learning: Learning grasp strategies through trial and error in simulation, then transferring to the real hand.
What problems remain unsolved?
Several open problems remain in humanoid robot hand design:
- In-hand manipulation: Rotating or repositioning objects within the hand without setting them down. Most current hands can grasp objects but have limited ability to reorient them.
- Durability: Dexterous hands with many moving parts are prone to mechanical wear, especially tendon-driven systems. Industrial deployment requires hands that survive thousands of hours of operation. Figure cited durability as a top reason for developing its tactile sensors in-house.[5]
- Cost: High-DOF dexterous hands with tactile sensing are expensive to manufacture. Reducing cost while maintaining performance is an active area of work.
- Generalization: Hands trained on specific objects or tasks often struggle with novel objects. Building hands and controllers that generalize across a wide range of household and industrial objects remains difficult.
Continue reading
- Dexterous handA dexterous hand (also called a dexterous robotic hand or multi-fingered robot hand) is an anthropomorphic end effector that reproduces the grasping, in-hand manipulation, and tactile perception of the human…Mentioned 22 times above
- Humanoid Robot"Humanoid" redirects here. For the London-based robotics company, see Humanoid (company).Mentioned 14 times above
- Degrees of FreedomDegrees of freedom (DoF) count independent ways in which a system, estimate, or model can vary, but the phrase does not denote one universal quantity.Mentioned 10 times above
- XynovaXynova (Chinese: 曦诺未来, also rendered Xynova Future) is a Hangzhou-based Chinese robotics startup, founded in December 2024 by Xia Yuxuan, that develops high-degree-of-freedom dexterous hands and the underlying…Mentioned 6 times above
- Tactile sensingTactile sensing is the technology that gives robots a sense of touch: the ability to measure the physical contact between a robot and the world, including contact force, pressure distribution, shear, slip…Mentioned 6 times above
- Xynova Flex 2The Xynova Flex 2 is the second-generation dexterous hand developed by Hangzhou-based robotics startup Xynova, publicly launched on May 13Mentioned twice above
More from See also
- Bionic hand
- ORCA Hand
- Sarcomere Dynamics
- Robot manipulation
- Xynova Flex 1
- Wuji Hand
- Linkerbot
- Tendon-driven actuation
- Imitation Learning
Topics:Humanoid Robots
References
- ^1 ^2 ^3 ^4 ^5 ^6 ^7HumanoidSpecs - Robot Hands Database
- ^1 ^2 ^3 ^4 ^5"Sanctuary AI integrates tactile sensors into Phoenix general purpose robots." The Robot Report, February 26, 2025. therobotreport.com/...oenix-general-purpose-robots
- ^1 ^2 ^3 ^4"Shadow Dexterous Hand." Shadow Robot Company, technical specification, 2025. shadowrobot.com/dexterous-hand-series
- ^1 ^2 ^3 ^4"Tesla Optimus Gen 3 Hands: 22-DoF, 50 Actuators Explained." Basenor, 2026. basenor.com/...hands-22-dof-50-actuators-explained
- ^1 ^2 ^3 ^4"Introducing Figure 03." Figure AI, October 2025. figure.ai/...introducing-figure-03
- ^1 ^2"Sanctuary AI Demonstrates In-Hand Manipulation Capabilities for Improved General Purpose Robot Dexterity." Sanctuary AI, December 2024. sanctuary.ai/...ed-general-purpose-robot-dexterity
- ^1 ^2"From Prototypes to Production: Dexterous Hands Kick Off a Mass-Production Race." Gasgoo Auto News, 2026. autonews.gasgoo.com/...on-race-2016425582734970881
- ^"Kinematics of human hand and robotics applications." International Journal of Science and Research Archive, 2024. ijsra.net/...IJSRA-2024-1441.pdf
- ^1 ^2"Chinese Robotics Startup Xynova Raises Over US$13 Million in Angel Round for High-DOF Dexterous Hands." TMTPost, December 26, 2025. en.tmtpost.com/...7822011
- ^1 ^2"Xynova Flex 2 product page." Xynova official site, 2026. xynova.com.cn/en
- ^"Xynova Flex 2 Robotic Hand." Aihola, May 2026. aihola.com/...xynova-flex-2-robotic-hand
- ^1 ^2RoboHub, X post on Xynova Flex 2, May 13, 2026. x.com/...2054454926382862838
- ^1 ^2"Led by Top Internet Giant, Xynova Closes Pre-A Round." Gasgoo Auto News, March 20, 2026. autonews.gasgoo.com/...a-round-2034985780127100928
- ^"Wuji Tech Confirmed as Hardware Partner for Genesis AI's Human-Level Dexterity Breakthrough." Humanoids Daily, May 7, 2026 (updated). humanoidsdaily.com/...level-dexterity-breakthrough
- ^"GENE-26.5: Advancing robotic manipulation to human level." Genesis AI blog, May 2026. web.archive.org/...tic-manipulation-to-human-level
Improve this article
Add missing citations, update stale details, or write a clearer explanation. Anyone can edit: changes go live when you publish, and every edit is checked by an editor.
12 revisions · v12 · 4,716 words · full history
Fact-checks are independent of edits: a reviewer re-verifies the article against its sources and stamps the date. How we verify
Research and drafting on this wiki are AI-assisted, under named human editorial standards. How AI is used here
Reviewer note: Independent fact-check of the full article against its cited sources (175 claims, 17 sources fetched); 18 material + 11 minor fixed
Cite this page: AI Wiki. "Humanoid robot hands." aiwiki.ai, updated 27 Oct 2026. CC BY 4.0. https://aiwiki.ai/wiki/humanoid_robot_hands